
Humanize Robotics
Grasping Mechanisms of Anthropomimetic Fingertips
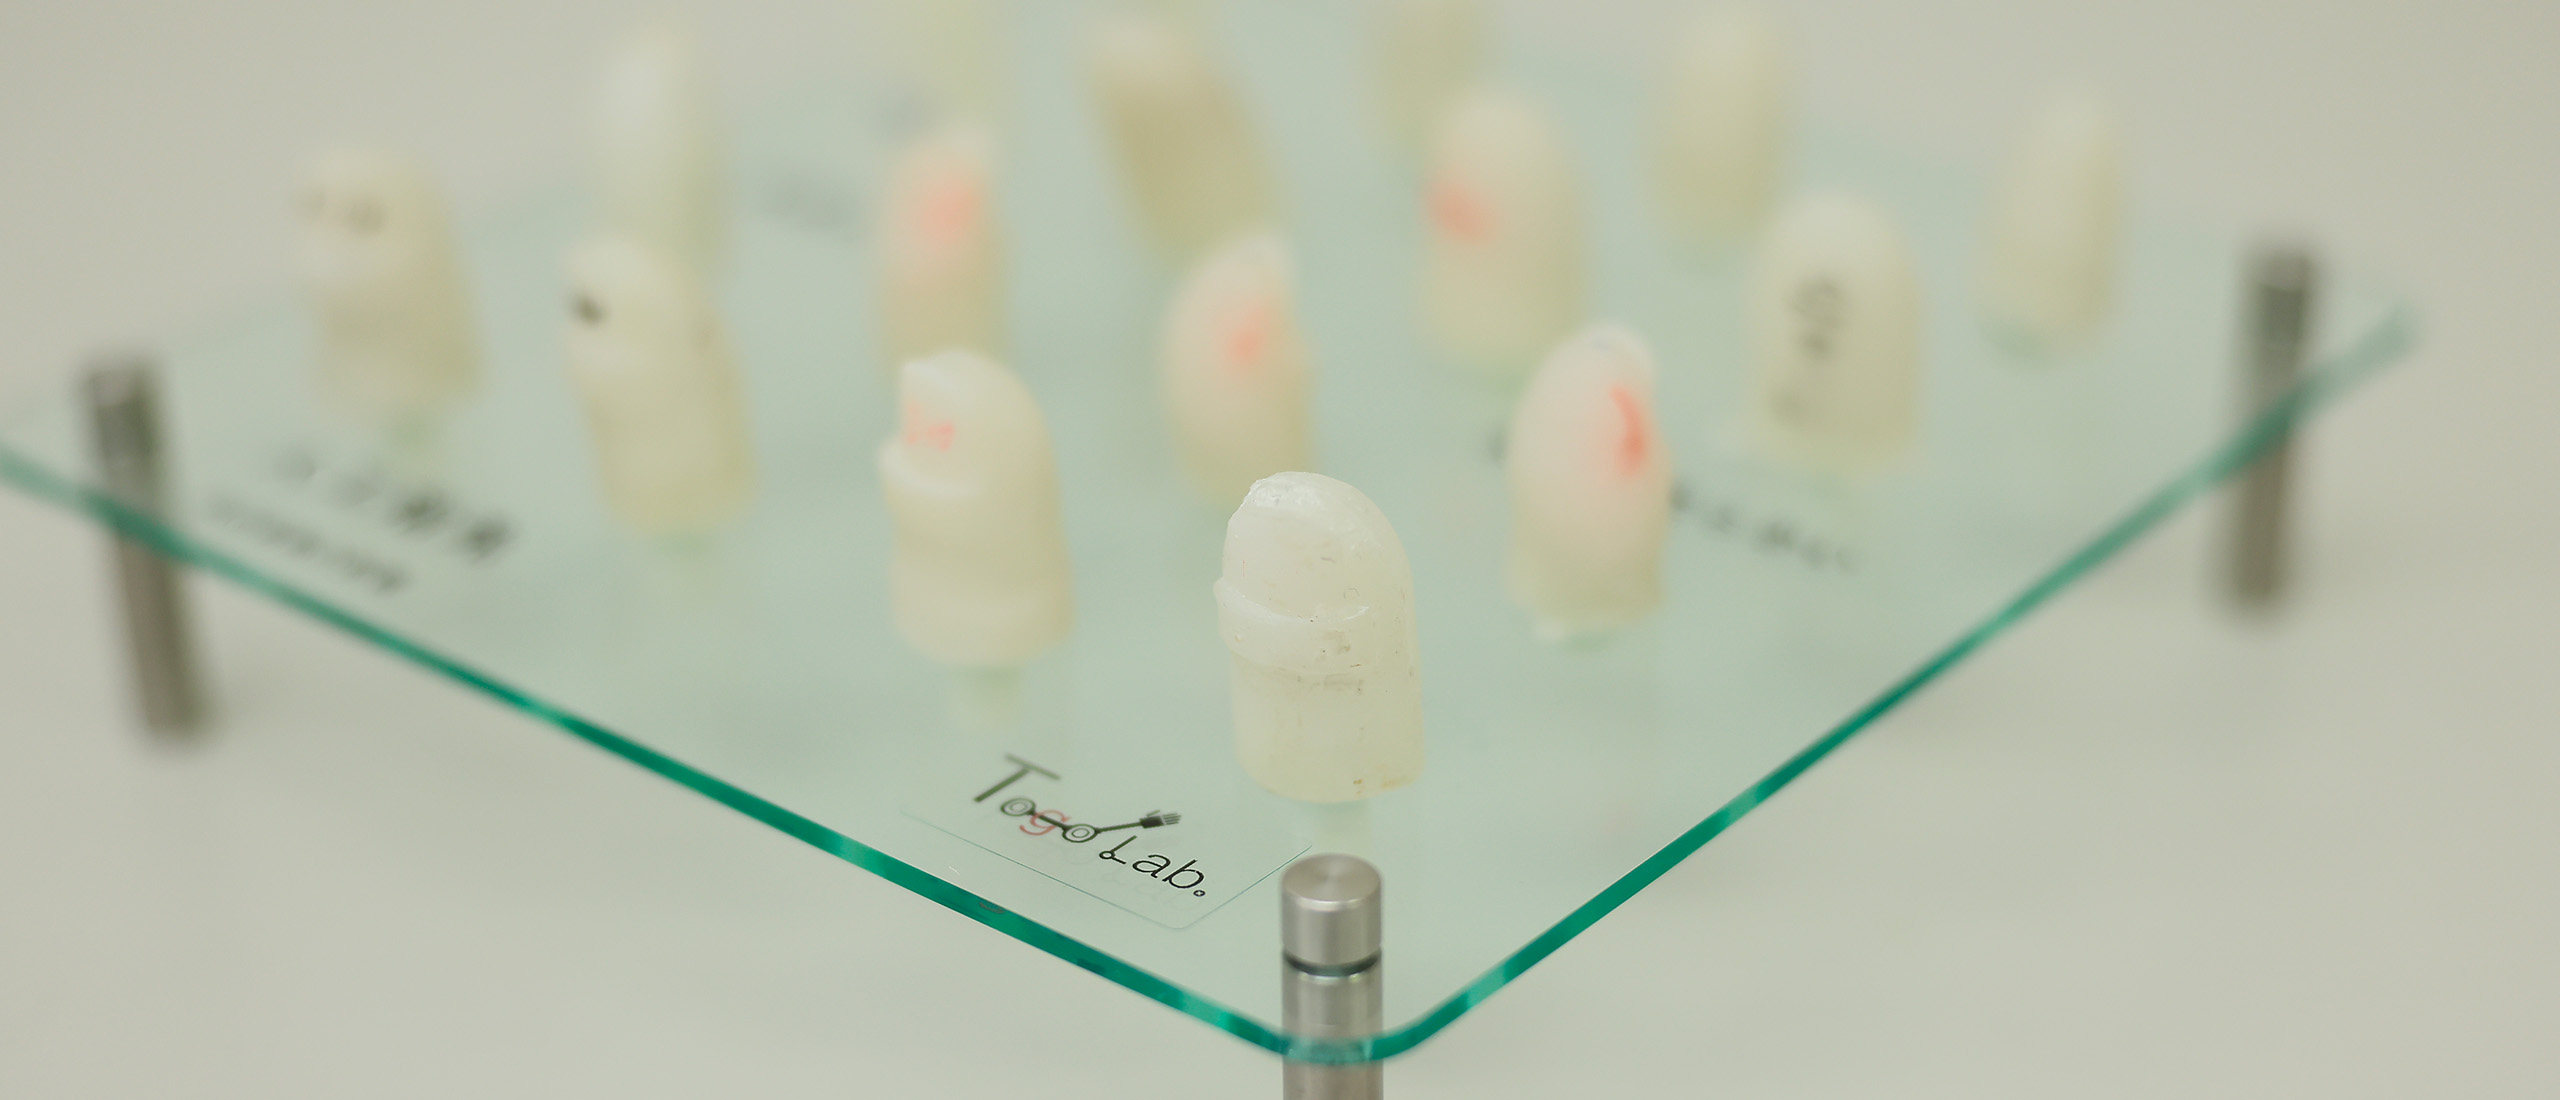
Using robotic fingers that mimic the shape and compliance of the human fingertip (nail, finger pulp, bone, and subcutaneous tissue), we investigate the fingertip functions that enable dexterous grasping. We also apply the findings to prosthetic hands.
Current members: Yuuta FUKASHIRO (M2) · Honori HAGIWARA (M1) · Koh YAOYA (B4)
Anthropomimetic Fingertip
2018 – present
Overview
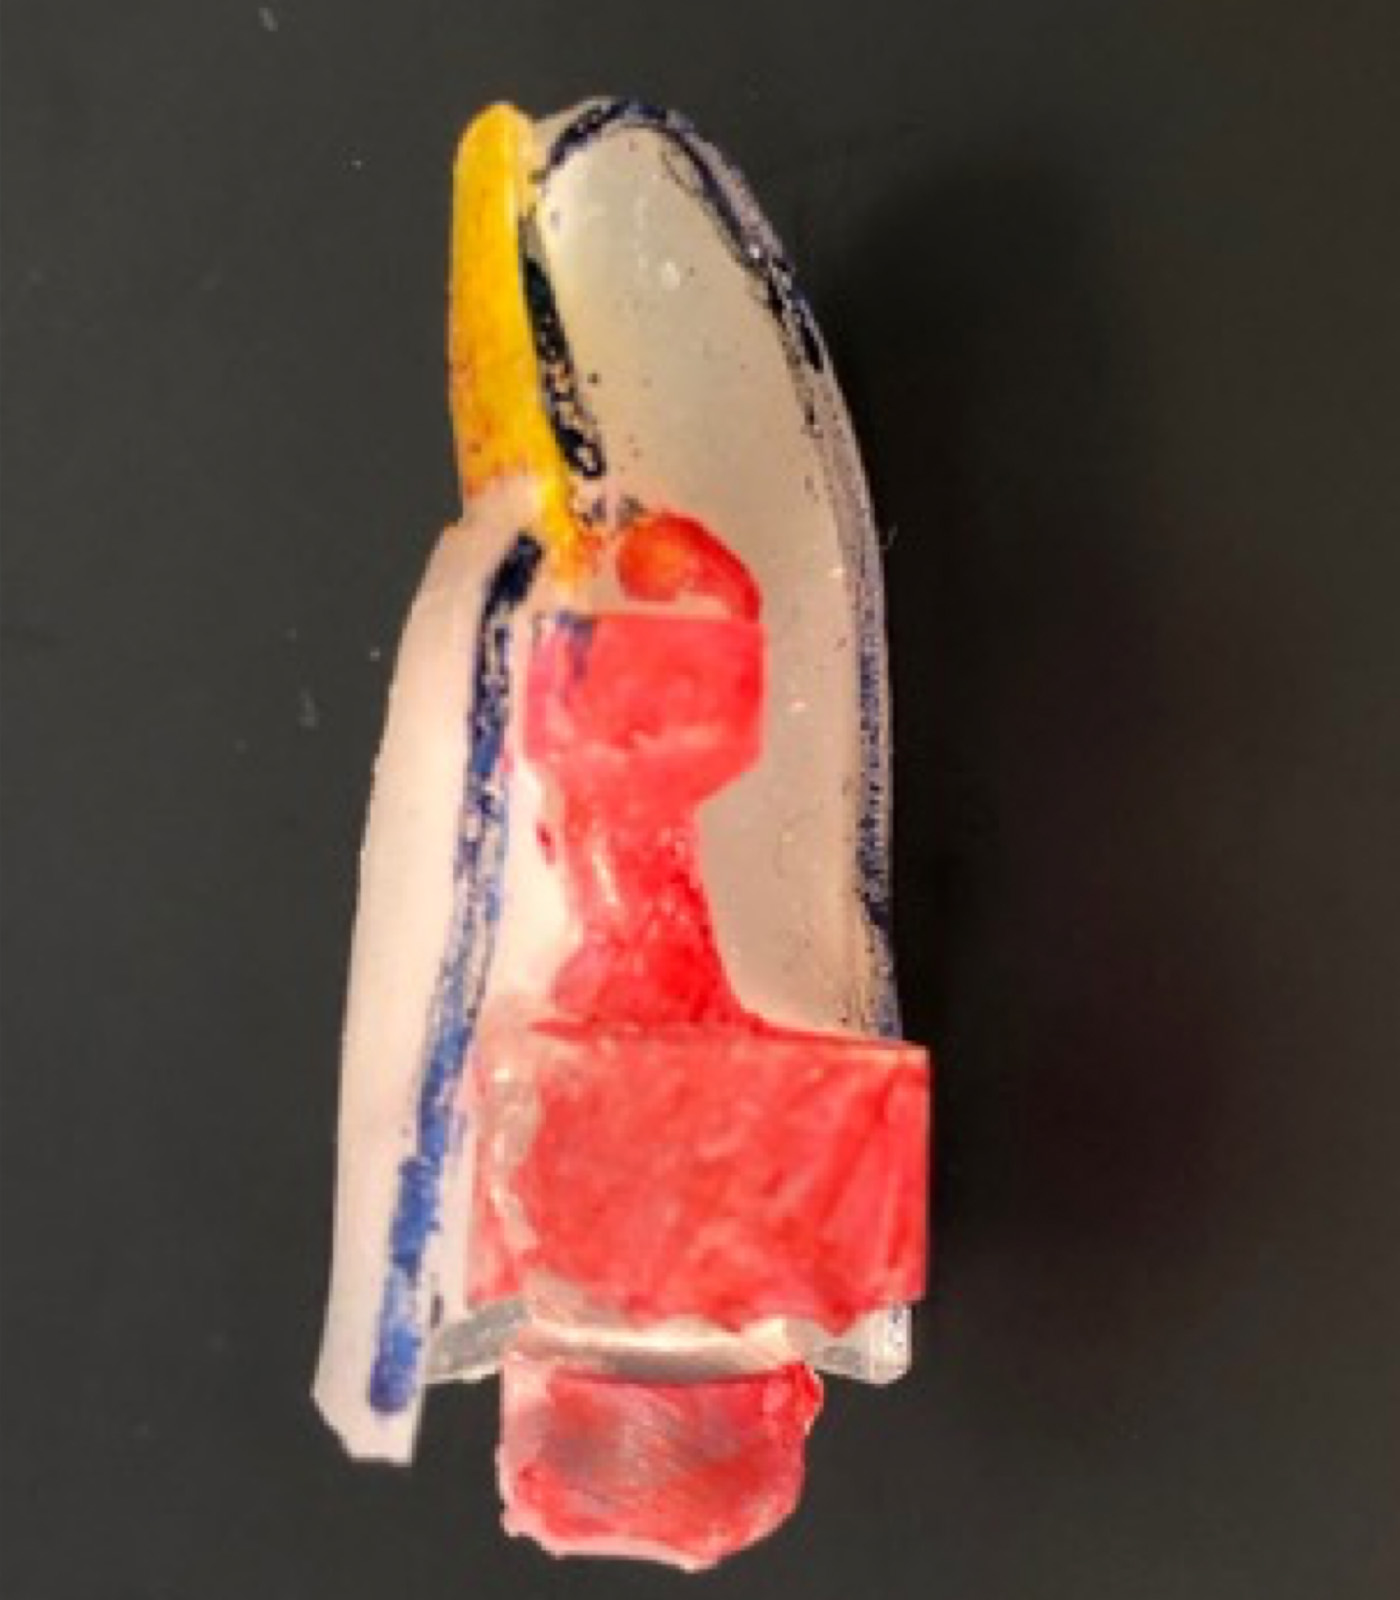
The human fingertip achieves precise grasping through the combination of fine structures: the distal phalanx, nail, finger pulp, and subcutaneous tissue. We build artificial fingertips that mimic these structures and constructively elucidate the fingertip functions that generate grasping performance.
Technical Features
- Faithfully reproduces the shapes of the distal phalanx, nail, finger pulp, and subcutaneous tissue
- Two-layer soft structure: soft skin over even softer subcutaneous tissue
- Design data for the fingertip and the coin-grasping apparatus released as open source on GitHub
Specifications
- Structure: distal phalanx, nail, finger pulp, and subcutaneous tissue
- Materials: 3D-printed bones and nail + silicone soft tissue
- Design: adaptable to robot hands and prosthetic hands by changing the bone base
Results
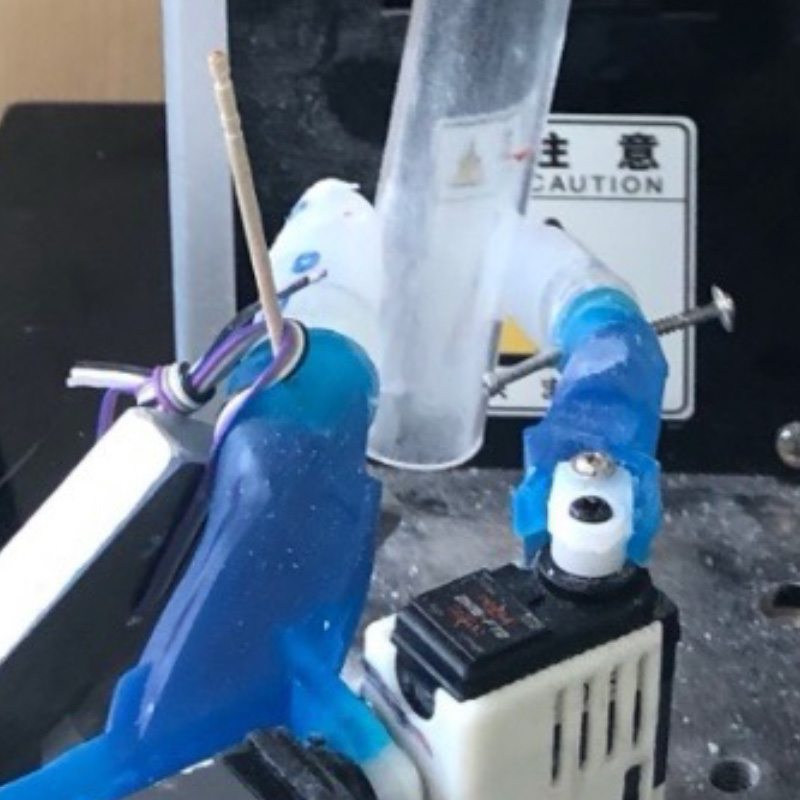
Revealed that the asymmetric shape of the distal phalanx improves precision grasping
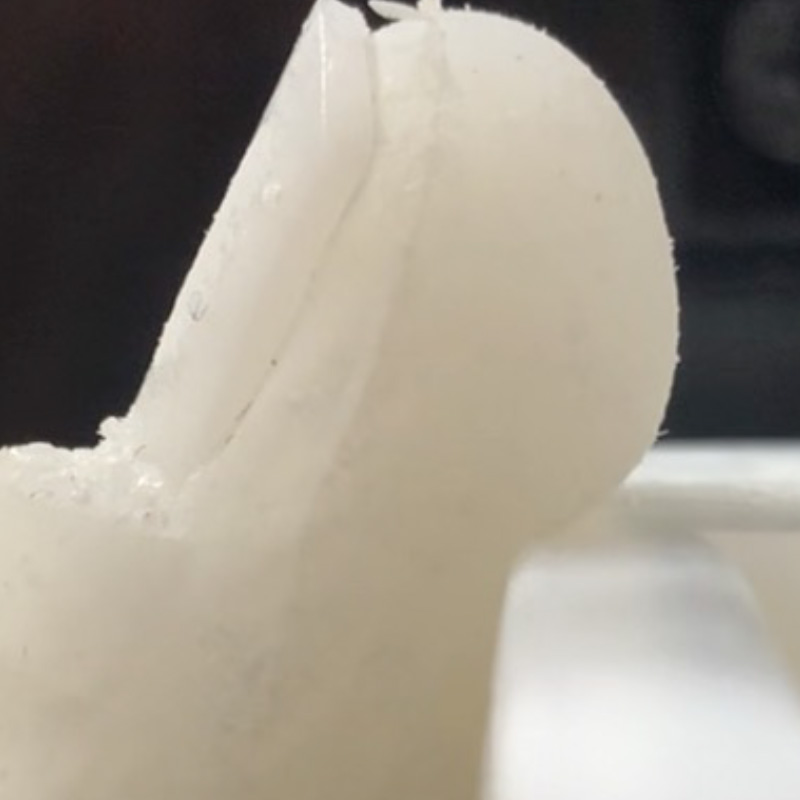
Revealed that the interaction between the soft finger pulp and the hard nail improves precision grasping
Revealed that skin with mixed stiffness distribution improves coin-grasping performance
Related Videos (in Japanese)
2019年度 卒論 ヒト指末節骨の形態的特徴に基づいた人工指による精密把持性能の評価
2021年度 修論 人体模倣柔軟指の精密把持性能に関する研究
2023年度 卒論 柔軟な人工指の指腹を用いた硬貨把持に関する研究
Related Publications
Journal Papers
中村 裕哉,呉 開元,井上 祐希,E. Tonatiuh Jimenez-Borgonio,矢吹 佳子,東郷 俊太,横井 浩史,"同一形状部材による劣駆動指屈曲メカニズムを有する義手用ロボットハンドの開発",日本ロボット学会誌,早期公開,2026.1.23. (in Japanese)
International Conference Papers
Ayane Kumagai, Yoshinobu Obata, Yoshiko Yabuki, Yinlai Jiang, Yokoi Hiroshi and Shunta Togo, “Comparison of precision grasping performance between artificial fingers with and without nails,” 2022 IEEE 4th Global Conference on Life Science and Technologies (LifeTech2022), pp. 380–381, Osaka, Japan, 7-9 Mar. 2022.
Ayane Kumagai, Yoshinobu Obata, Yinlai Jiang, Hiroshi Yokoi and Shunta Togo, “Evaluation of the grasping ability by artificial finger based on the morphology of distal phalanx,” 2020 IEEE 2nd Global Conference on Life Science and Technologies (LifeTech 2020), pp. 334-335, Kyoto Japan, 10–12 Mar. 2020.
Yoshinobu Obata, Ayane Kumagai, Shunta Togo, Yinlai Jiang and Hiroshi Yokoi, “Analysis of two-layer artificial soft fingertip for dynamic stable grasping,” 2020 IEEE 2nd Global Conference on Life Science and Technologies (LifeTech 2020), pp. 362-363, Kyoto Japan, 10–12 Mar. 2020.