Humanize Robotics
Humanize Robotics
Laboratory
Togo Laboratory — from the embodied intelligence of the human body to the mechanism intelligence of robots
Department of Mechanical and Intelligent Systems Engineering,
Graduate School of Informatics and Engineering, The University of Electro-Communications
About Us
About Us

Research Keywords
Welcome to Togo Laboratory
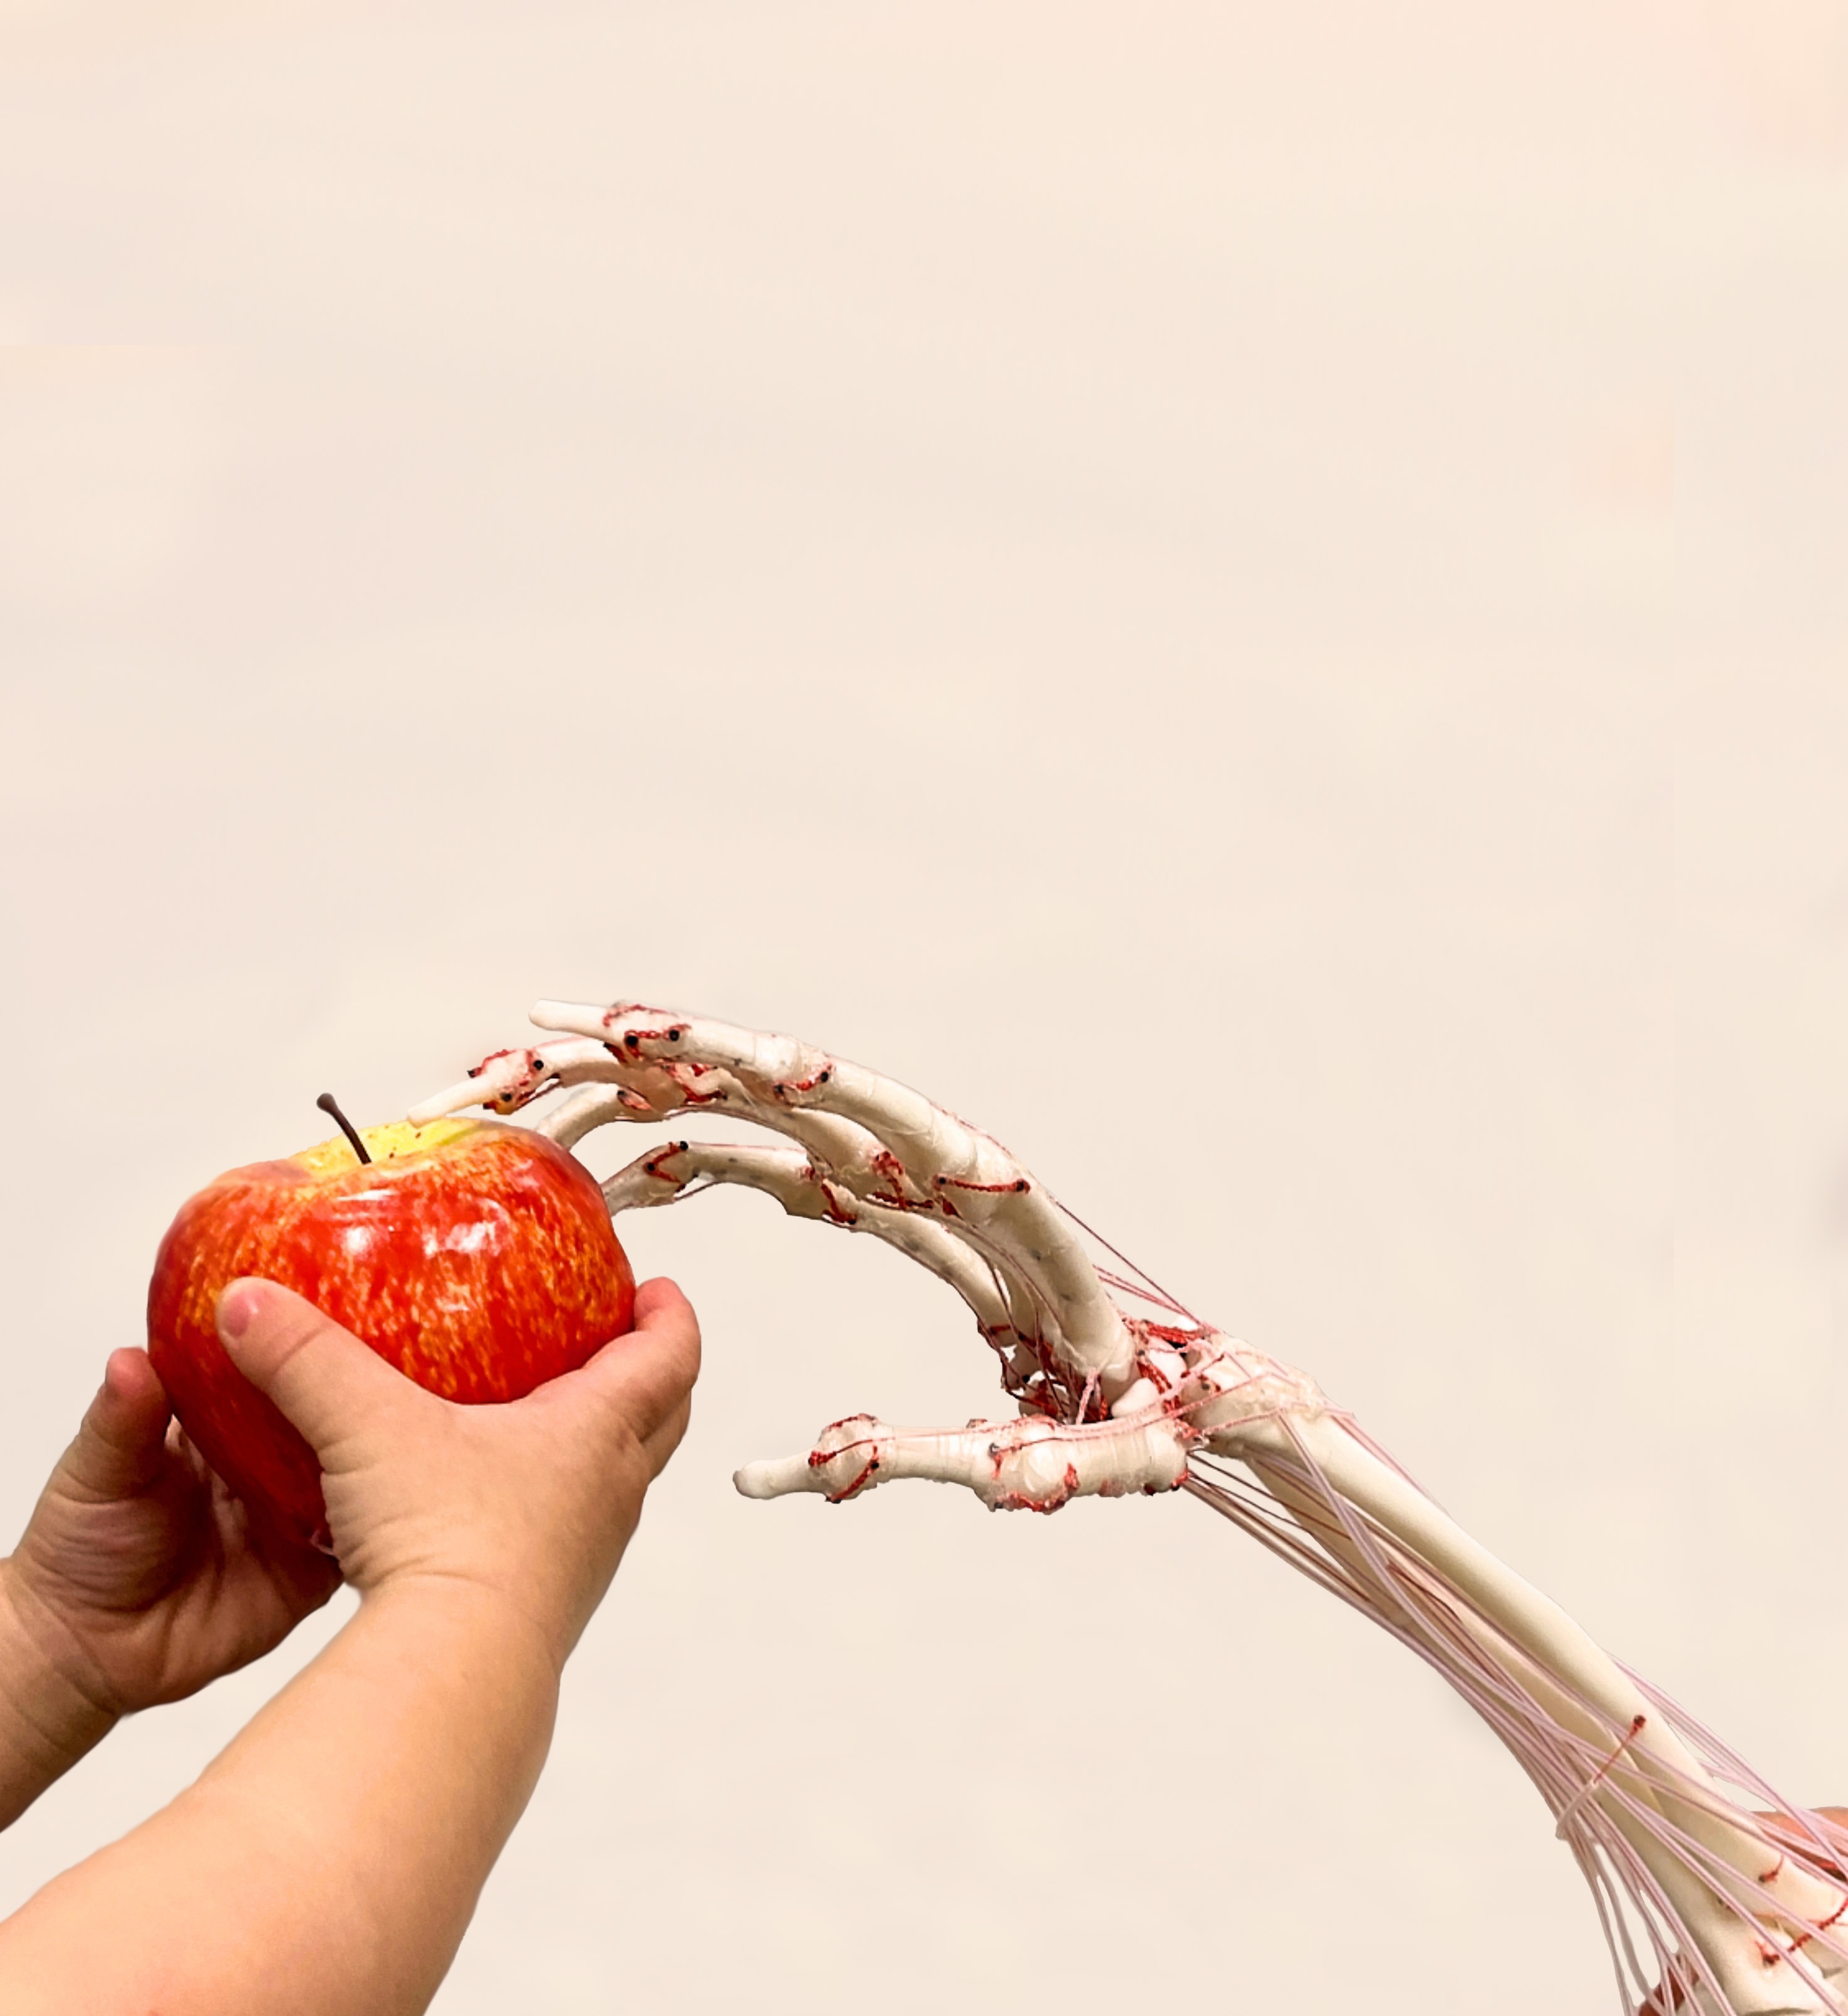
Togo Laboratory aims to establish "Humanize Robotics" — a discipline that elucidates the intelligence residing in the human body through anthropomimetic robots and applies it to engineering.
We build anthropomimetic robots that faithfully reproduce human skeletal, muscular, and ligament structures to constructively understand Embodied Intelligence — the intelligence generated by the morphology of the human body. We then extract Principle Intelligence that does not depend on the specific human form, and translate it into simpler, highly implementable mechanisms as Mechanism Intelligence for practical devices such as prosthetic hands, robot hands, and robotic arms.
In this process, an anthropomimetic robot is not a mere copy of the human body. By artificially building, actuating, and comparing structures close to the human body, we can examine structure–function relationships that are difficult to verify directly in humans. The differences that arise in reproduction also provide important clues to how human morphology generates function.
Covering everything from understanding the human body to engineering implementation, our research spans robotics, neuroscience, physiology, measurement engineering, and machine learning — and trains people who can view complex body systems from multiple perspectives.
Research Projects
Research Projects
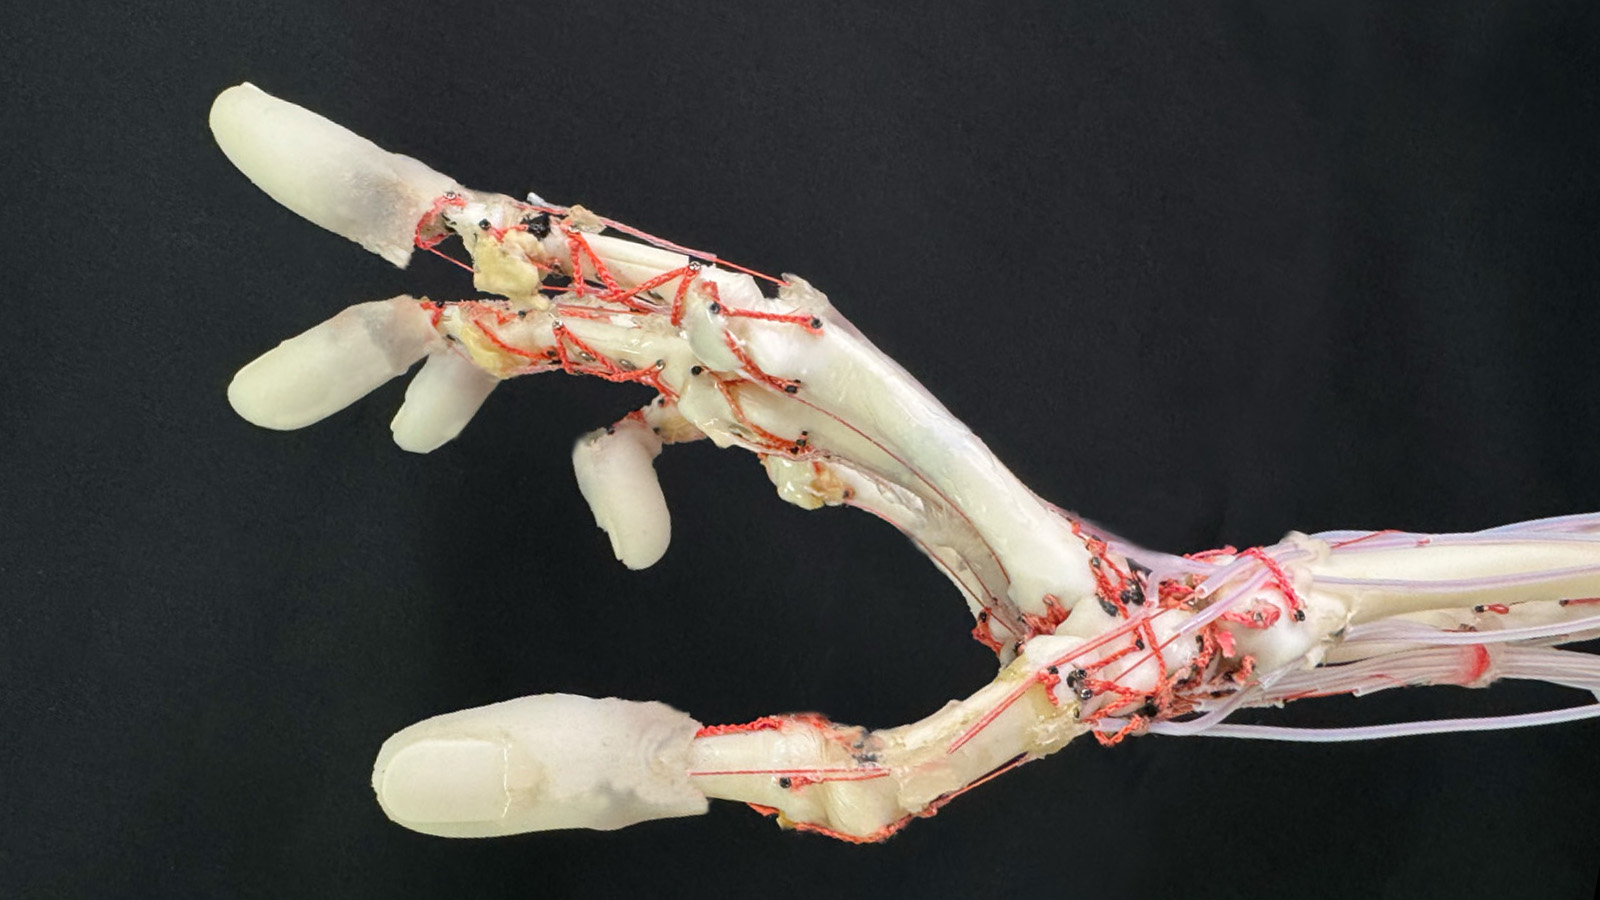
R&D of Anthropomimetic Forearm and Hand
We build robotic forearms and hands that faithfully mimic human skeletal, muscular, and tendon structures to constructively investigate the mechanisms underlying human dexterity.
Learn more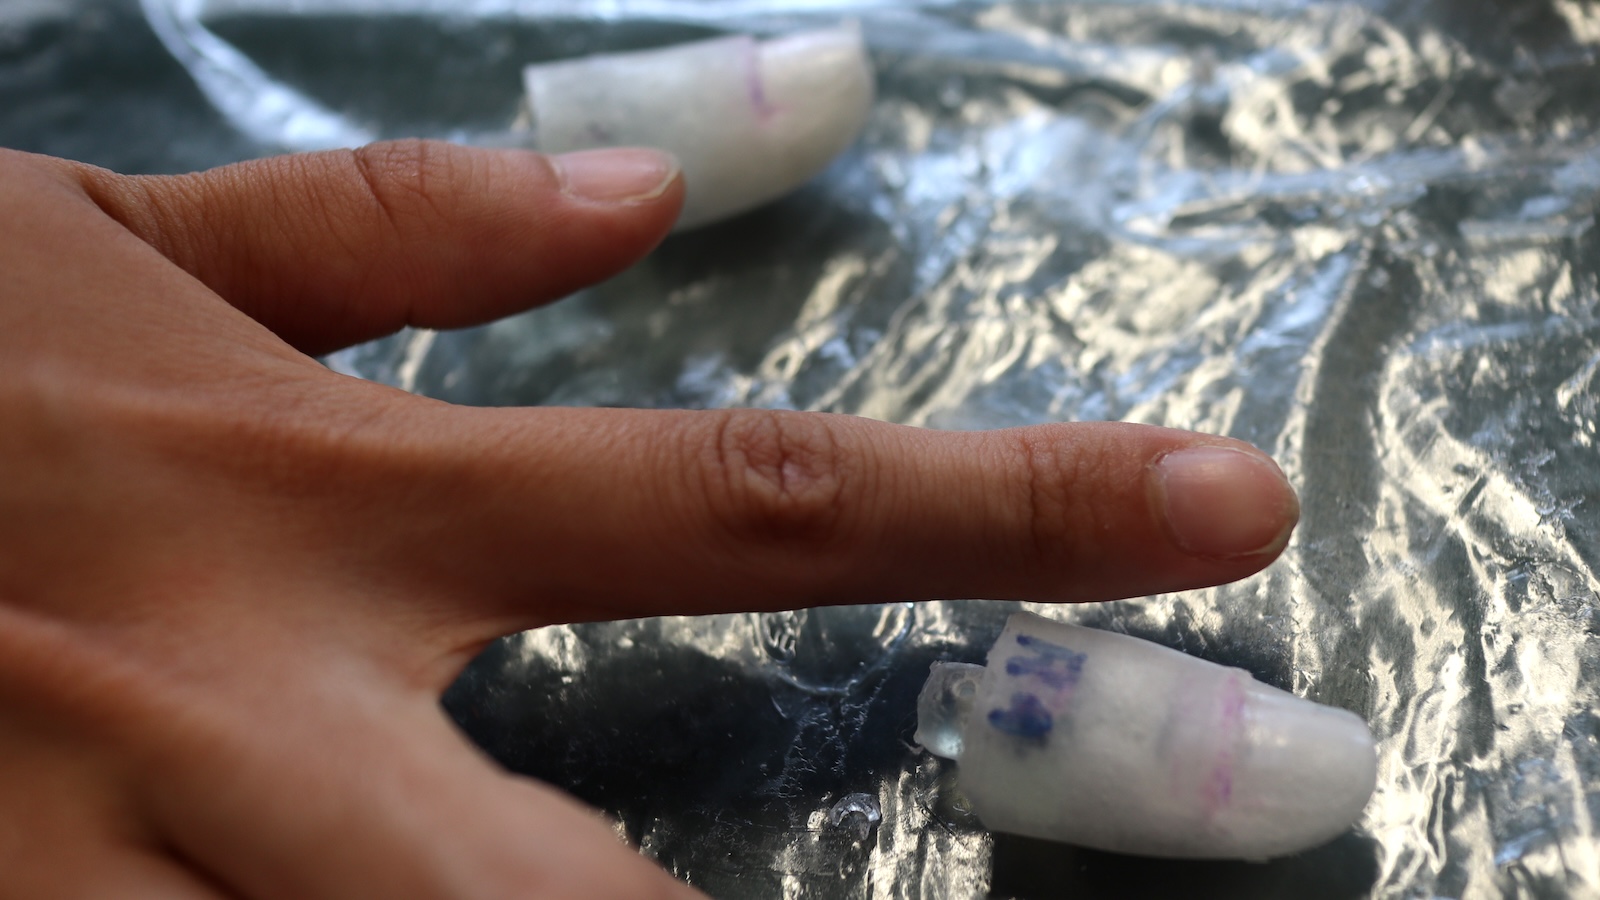
Grasping Mechanisms of Anthropomimetic Fingertips
Using robotic fingers that mimic the shape and compliance of the human fingertip (nail, finger pulp, bone, and subcutaneous tissue), we investigate fingertip functions that enable dexterous grasping, with applications to prosthetic hands.
Learn more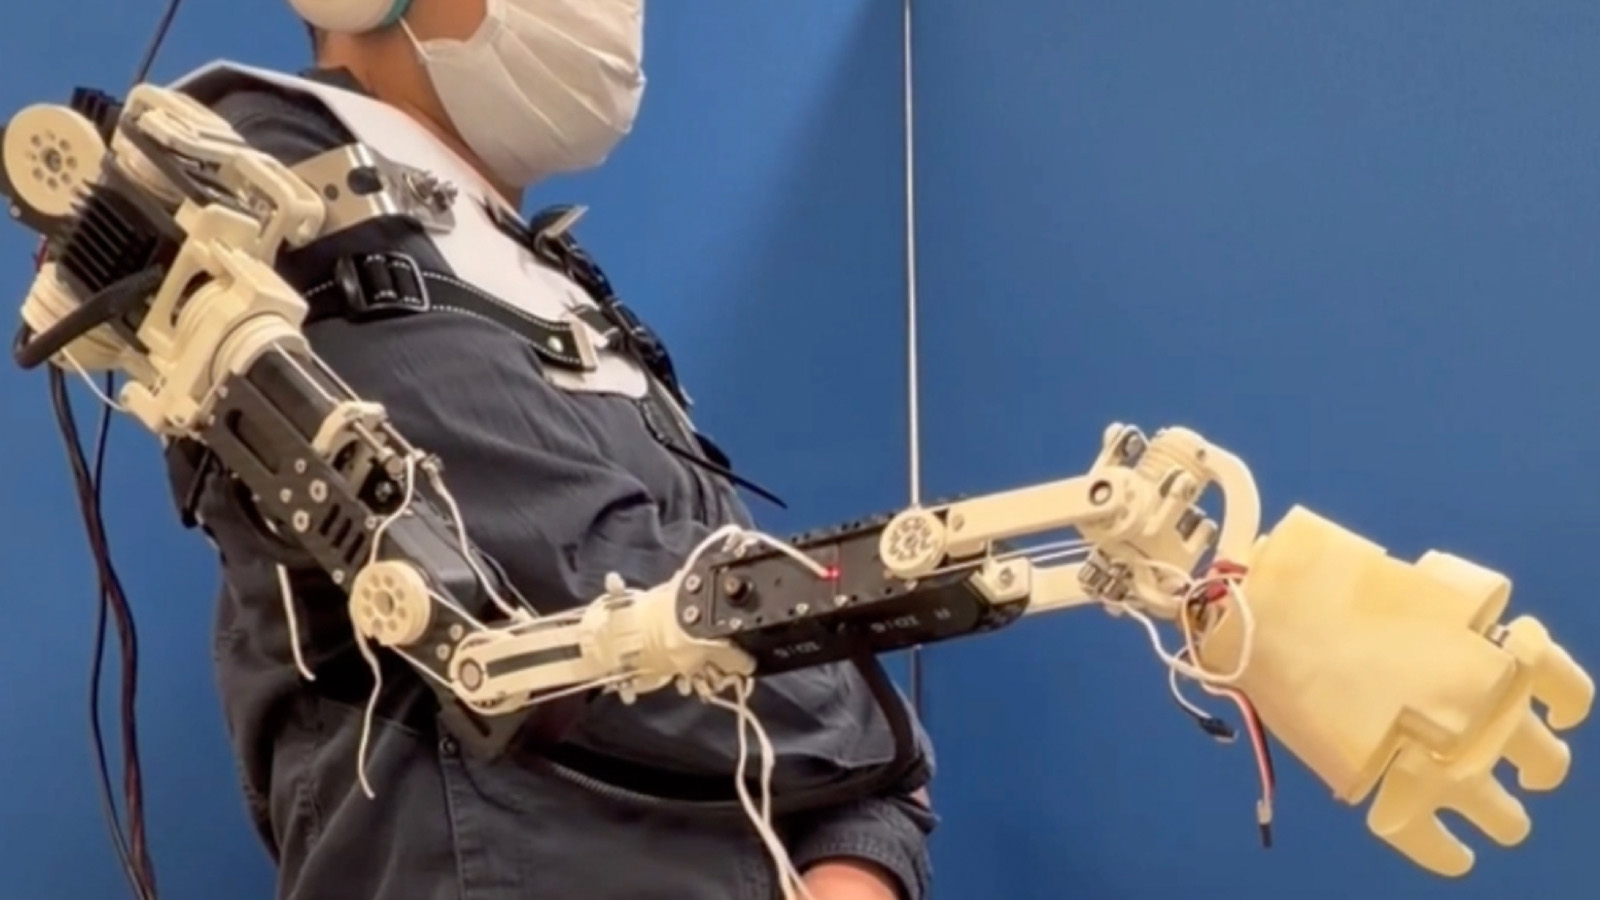
R&D of Electric Shoulder Prostheses
We develop myoelectric shoulder prostheses that reconstruct arm movements for people with shoulder disarticulation, covering robotic arms, hands, sensor systems, and control methods.
Learn more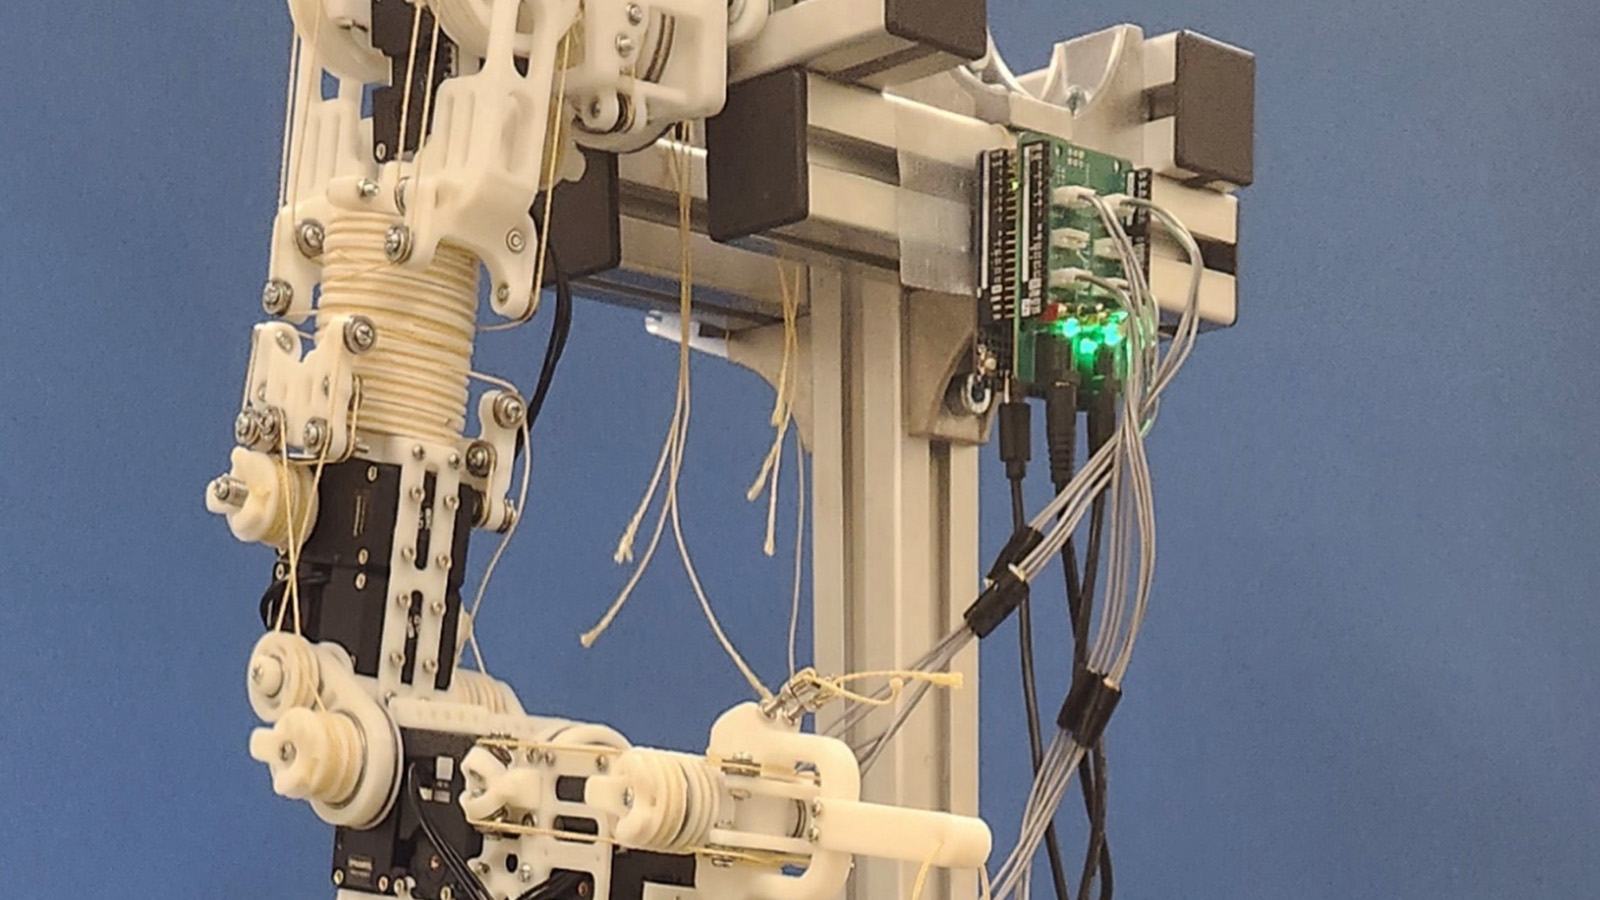
R&D of Fully Coupled Tendon-Driven Mechanisms
We develop the design theory and implementation of mechanisms in which every actuator output contributes to every joint, together with elemental technologies such as infinite wire-winding and gravity compensation mechanisms.
Learn more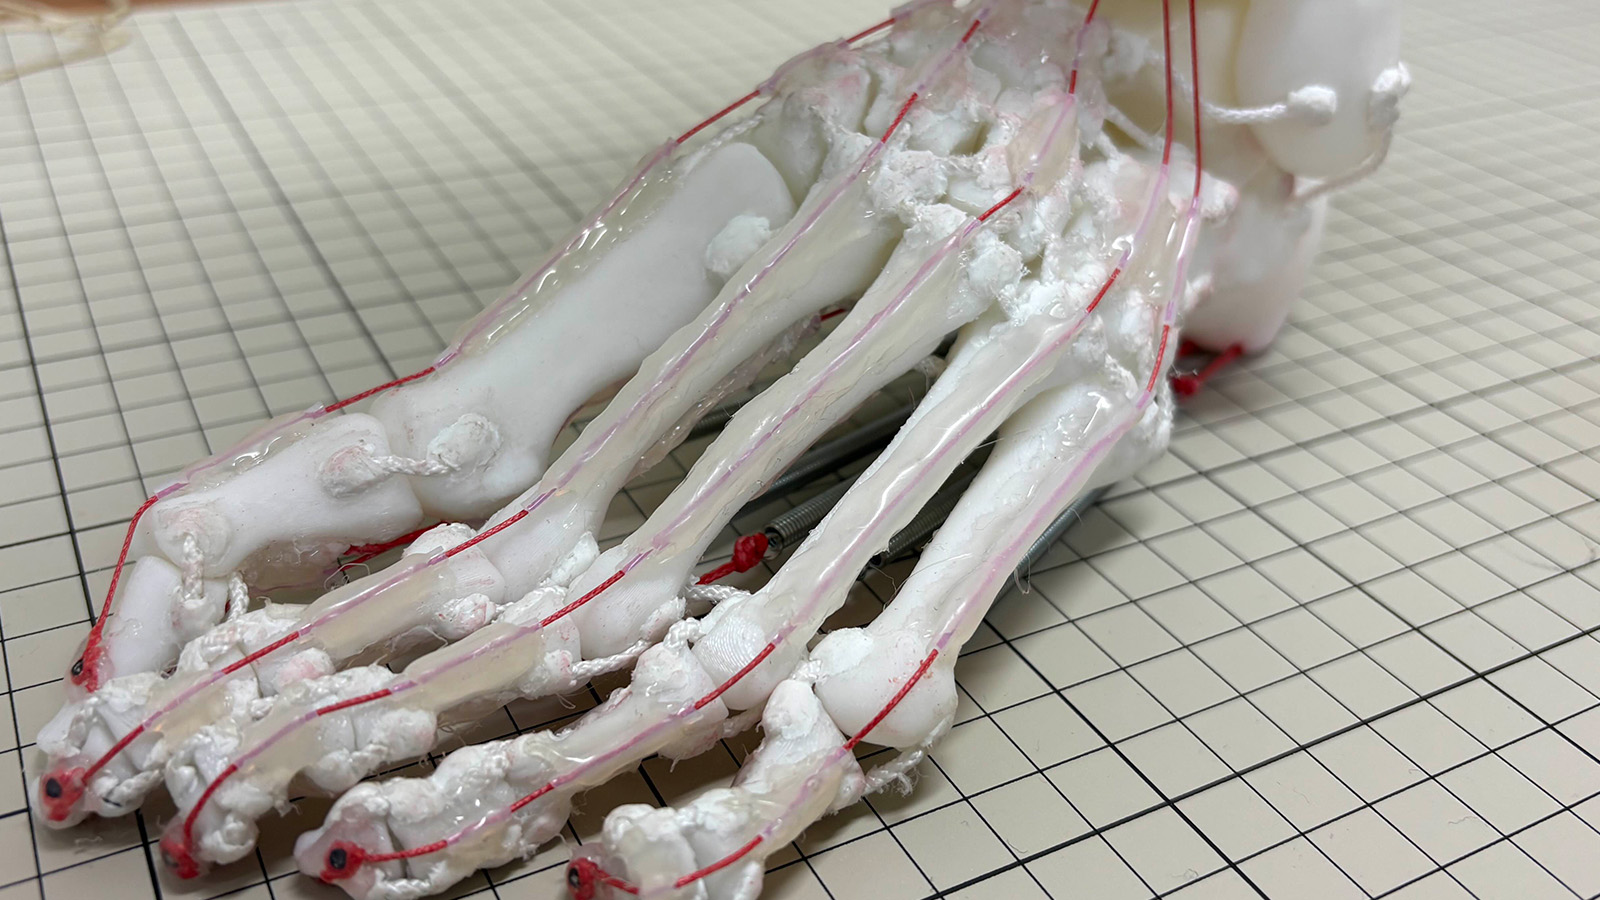
R&D of Anthropomimetic Foot and Leg
Using robots that mimic the skeletal and ligament structures of the human foot, we elucidate functions generated by foot morphology — such as shock absorption at landing and propulsion — and extend them to legged robots.
Learn more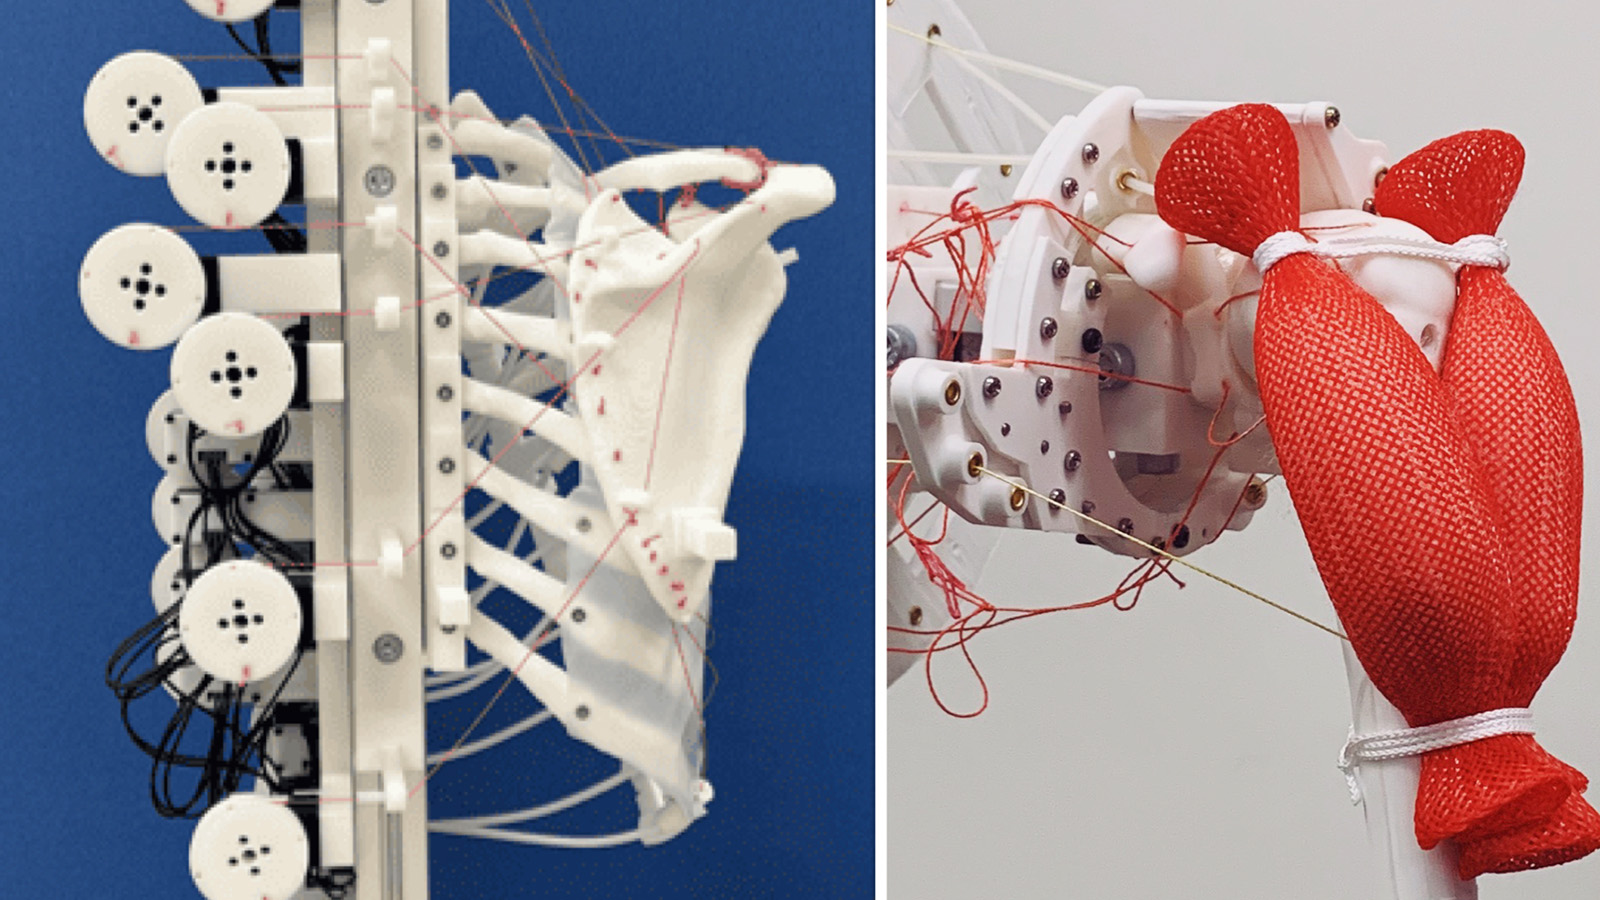
R&D of Anthropomimetic Shoulder Joints
Using robots that mimic the human glenohumeral and scapulothoracic joints, we investigate how the shoulder achieves both a wide range of motion and stability.
Learn moreR&D of Electric Shoulder Prostheses is supported by the machinery industry promotion subsidy of the JKA Foundation (KEIRIN race proceeds).
Members
Members
Associate Professor
Shunta TOGO
Research: Humanize Robotics, anthropomimetic robots, cyborg technology, computational neuroscience
Full profileDoctoral
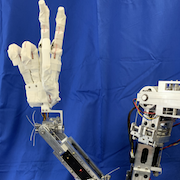
白 書霆 (Shuting BAI)
Multi-DoF robotic arm control
M2
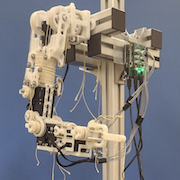
佐藤 裕騎 (Hiroki SATO)
Coupled tendon-driven robotic arm
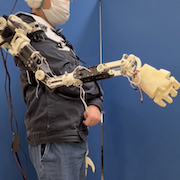
髙田 燎 (Ryo TAKADA)
Operation of multi-DoF shoulder prostheses
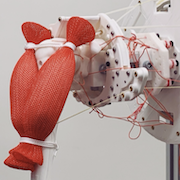
永澤 孔大 (Koudai NAGASAWA)
Anthropomimetic shoulder joint
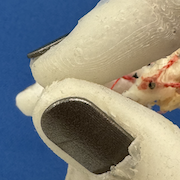
深代 悠太 (Yuuta FUKASHIRO)
Grasping with anthropomimetic fingers
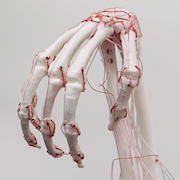
中村 光貴 (Kouki NAKAMURA)
Anthropomimetic hand
羅 聿洲 (Yuzhou LUO)
Control of coupled tendon-driven mechanisms
M1
竹田 知弘 (Tomohiro TAKEDA)
Anthropomimetic shoulder joint
萩原 帆紀 (Honori HAGIWARA)
Anthropomimetic fingertip
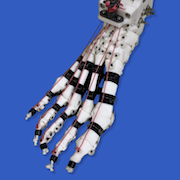
橋本 虹太 (Kota HASHIMOTO)
Anthropomimetic foot
渡邊 一太 (Itta WATANABE)
Anthropomimetic finger control
李 澤文 (Zewen LI)
Coupled tendon-driven mechanism
楊 之光 (Zhiguang YANG)
Human-normative wrist mechanism
B4
栗林 康誠 (Kose KURIBAYASHI)
Anthropomimetic hand
嶋村 悠 (Haru SHIMAMURA)
Anthropomimetic elbow joint
竹村 光貴 (Kouki TAKEMURA)
Anthropomimetic foot
八百屋 昂 (Koh YAOYA)
Tactile sensor
Research Students
陳 麒百 (Qibai CHEN)
余 辰皓 (Chenhao YU)
張 天昊 (Tianhao ZHANG)
Environment
Lab Environment
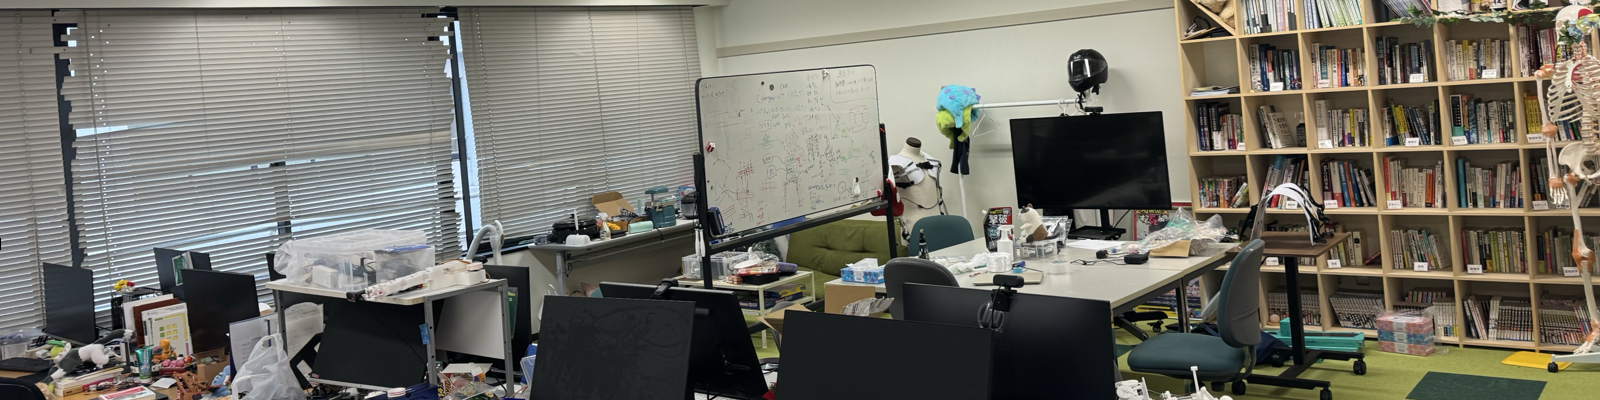
What the lab offers
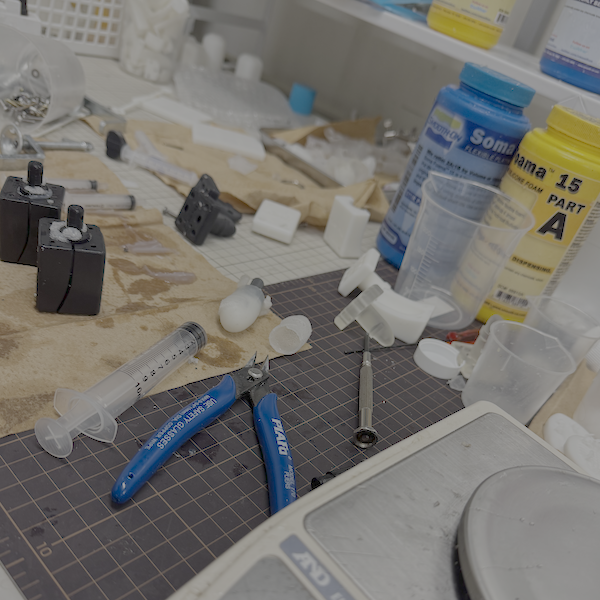
One desk per student, a lab PC on loan, and hands-on tools provided for everyone
Robots are built in-house from raw materials
Bi-weekly progress meetings (reported as online articles) plus a journal club every semester
Joint seminars and technical exchange with the Yokoi Lab and Jiang Lab
An environment where students can learn hands-on making and new knowledge
Our motto: the whole lab grows smarter together, passing on knowledge and skills
Lab policy
- ・We aim to be a lab where students enjoy research, making things, and building skills
- ・We invest in sharing and passing on knowledge so the whole lab grows smarter
- ・Joint seminars and technical exchange with the Yokoi Lab and Jiang Lab
- ・No core time and no restrictions on part-time jobs (but building hardware takes time — steady daily work is recommended)
- ・We use engineering as a tool for science
Regular events (example: 2nd semester)
Wed 13:00–15:00
Joint meeting of the Yokoi, Jiang, and Togo Labs (progress reports)
Online
Thu 10:40–12:10
Togo Lab meeting (progress reports)
Hybrid
Thu 12:15–13:00
Togo Lab journal club (paper reading)
Hybrid
Lab infrastructure
Publications
Publications
中村 裕哉,呉 開元,井上 祐希,E. Tonatiuh Jimenez-Borgonio,矢吹 佳子,東郷 俊太,横井 浩史,"同一形状部材による劣駆動指屈曲メカニズムを有する義手用ロボットハンドの開発",日本ロボット学会誌,早期公開,2026.1.23. (in Japanese)
Dian Li, Peiji Chen, Shunta Togo, Hiroshi Yokoi, Yinlai Jiang, "FESNet: A fine-grained EMG segmentation network for enhanced finger movement analysis," 2025 IEEE International Conference on Systems, Man, and Cybernetics (SMC), pp. 4597-4602, Vienna, Austria, Oct. 5–8, 2025.
Peiji Chen, Yifan Tang, Dian Li, Hai Jiang, Shunta Togo, Hiroshi Yokoi, Yinlai Jiang, "Advanced data augmentation techniques for biosignal processing in online systems," 2025 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM), Hangzhou, China, Jul. 14–18, 2025.
Josef Da Silva Bernardo Neto, Wenyang Li, Shunta Togo, Hiroshi Yokoi, Yinlai Jiang, “Model-based tension and state estimation for sensorless tendon-driven mechanisms,” 2024 IEEE International Conference on Advanced Robotics and Mechatronics (ICARM), Tokyo, Japan, Jul. 8–10, 2024.Best Conference Paper Finalist
Peiji Chen, Dian Li, Yifan Tang, Shunta Togo, Hiroshi Yokoi, Yinlai Jiang, “Dynamic Label Smoothing Strategy for Biosignal Classification,” 2024 IEEE International Conference on Acoustics, Speech and Signal Processing (ICASSP), pp.1556–1560, Seoul, Korea, Apr. 14–19, 2024.
Shuting Bai, Jiazhen Guo, Yinlai Jiang, Hiroshi Yokoi and Shunta Togo, “Automatic control system for reach-to-grasp movement of a 7-DOF robotic arm using object pose estimation with an RGB camera,” 2023 IEEE International Conference on Robotics and Biomimetics (ROBIO), Samui, Thailand, Dec. 4-9, 2023.
Yoshinobu Obata, Yinlai Jiang, Hiroshi Yokoi and Shunta Togo, “Design of anthropomimetic robotic wrist joint and forearm,” 2023 IEEE International Conference on Systems, Man, and Cybernetics (SMC), pp. 1766–1771, Oahu, Hawaii, USA, Oct. 1-4, 2023.
Join Us
Join Us
Would you like to join Togo Laboratory? We welcome anyone interested in robots, the human body, or making things. Lab tours are always welcome — please contact Dr. Togo.
s.togouec.ac.jp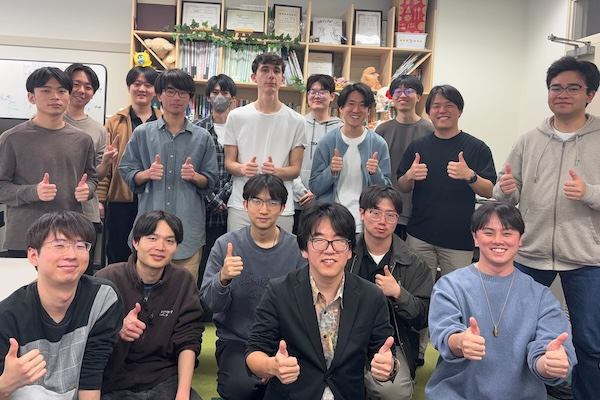
How to join
Bachelor’s degree
Join via the undergraduate thesis assignment in Program 5 (Advanced Robotics), Cluster II. We have accepted transfer students from technical colleges and GLTP students.
Master’s degree
Join by entering the Department of Mechanical and Intelligent Systems Engineering, Graduate School of Informatics and Engineering. We have accepted students from technical colleges, other universities, and abroad.
Doctoral degree
Join by entering the same department. We have accepted working professionals. Please contact us early to prepare a solid research plan.
Postdoc
JSPS postdoctoral fellows are welcome. We have facilities for robot fabrication and human motion measurement.