
Research Projects
Research Projects
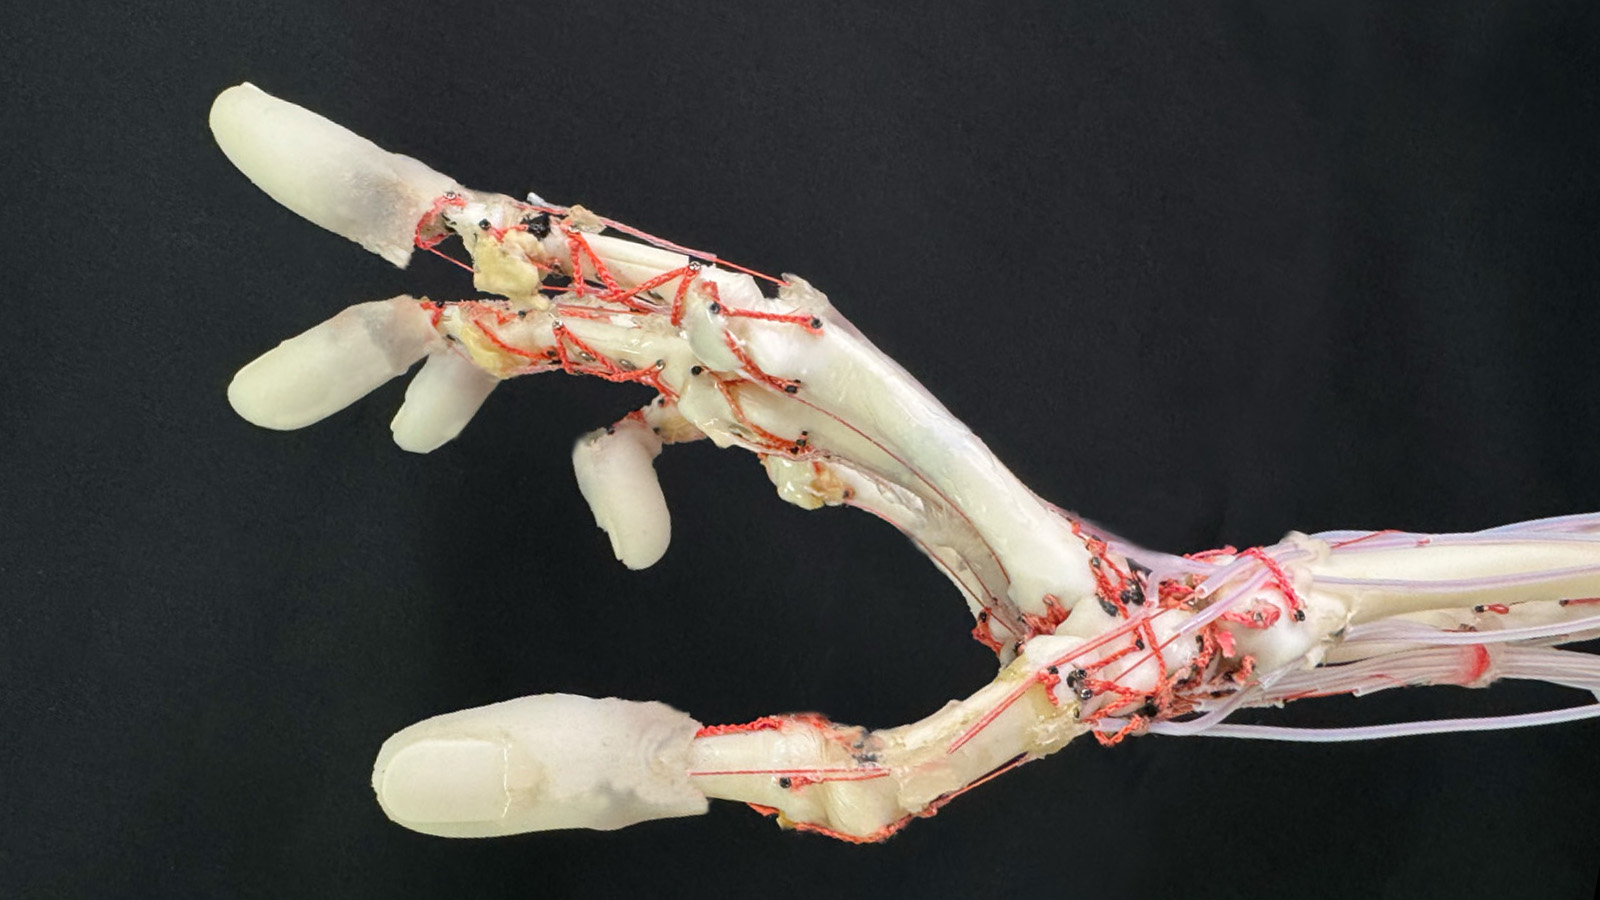
R&D of Anthropomimetic Forearm and Hand
We build robotic forearms and hands that faithfully mimic human skeletal, muscular, and tendon structures to constructively investigate the mechanisms underlying human dexterity.
Current members: Kouki NAKAMURA (M2) · Itta WATANABE (M1) · Kose KURIBAYASHI (B4) · Haru SHIMAMURA (B4)
Selected works: Obata et al., IEEE SMC, 2023, etc.
Learn more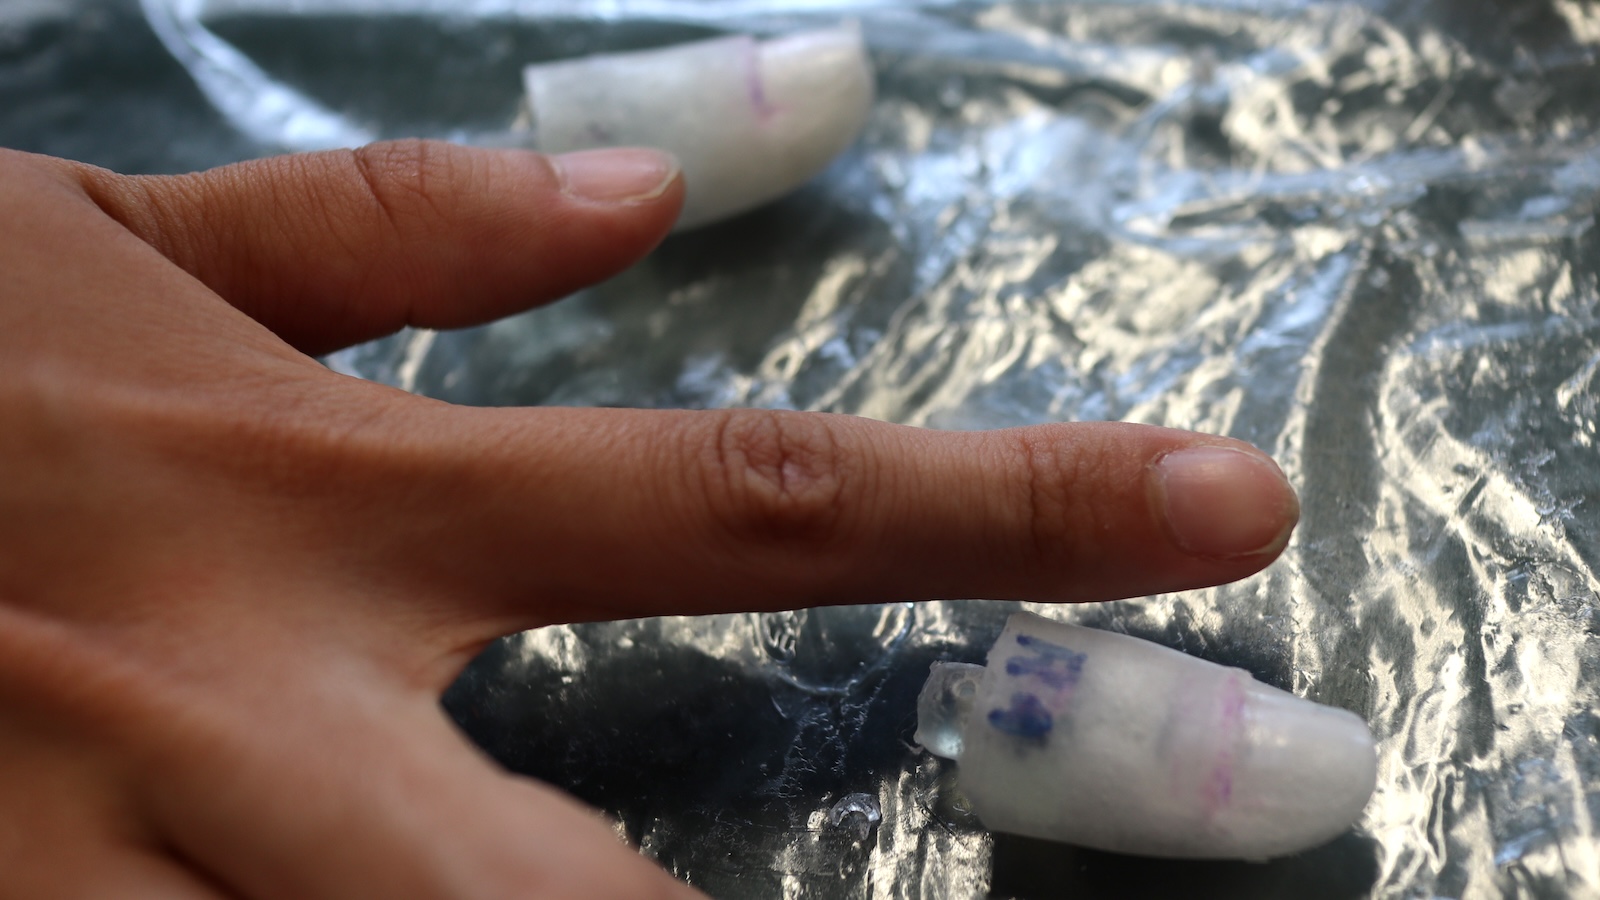
Grasping Mechanisms of Anthropomimetic Fingertips
Using robotic fingers that mimic the shape and compliance of the human fingertip (nail, finger pulp, bone, and subcutaneous tissue), we investigate fingertip functions that enable dexterous grasping, with applications to prosthetic hands.
Current members: Yuuta FUKASHIRO (M2) · Honori HAGIWARA (M1) · Koh YAOYA (B4)
Selected works: Kumagai et al., Soft Robotics, 2023 / Kumagai et al., Scientific Reports, 2021, etc.
Learn more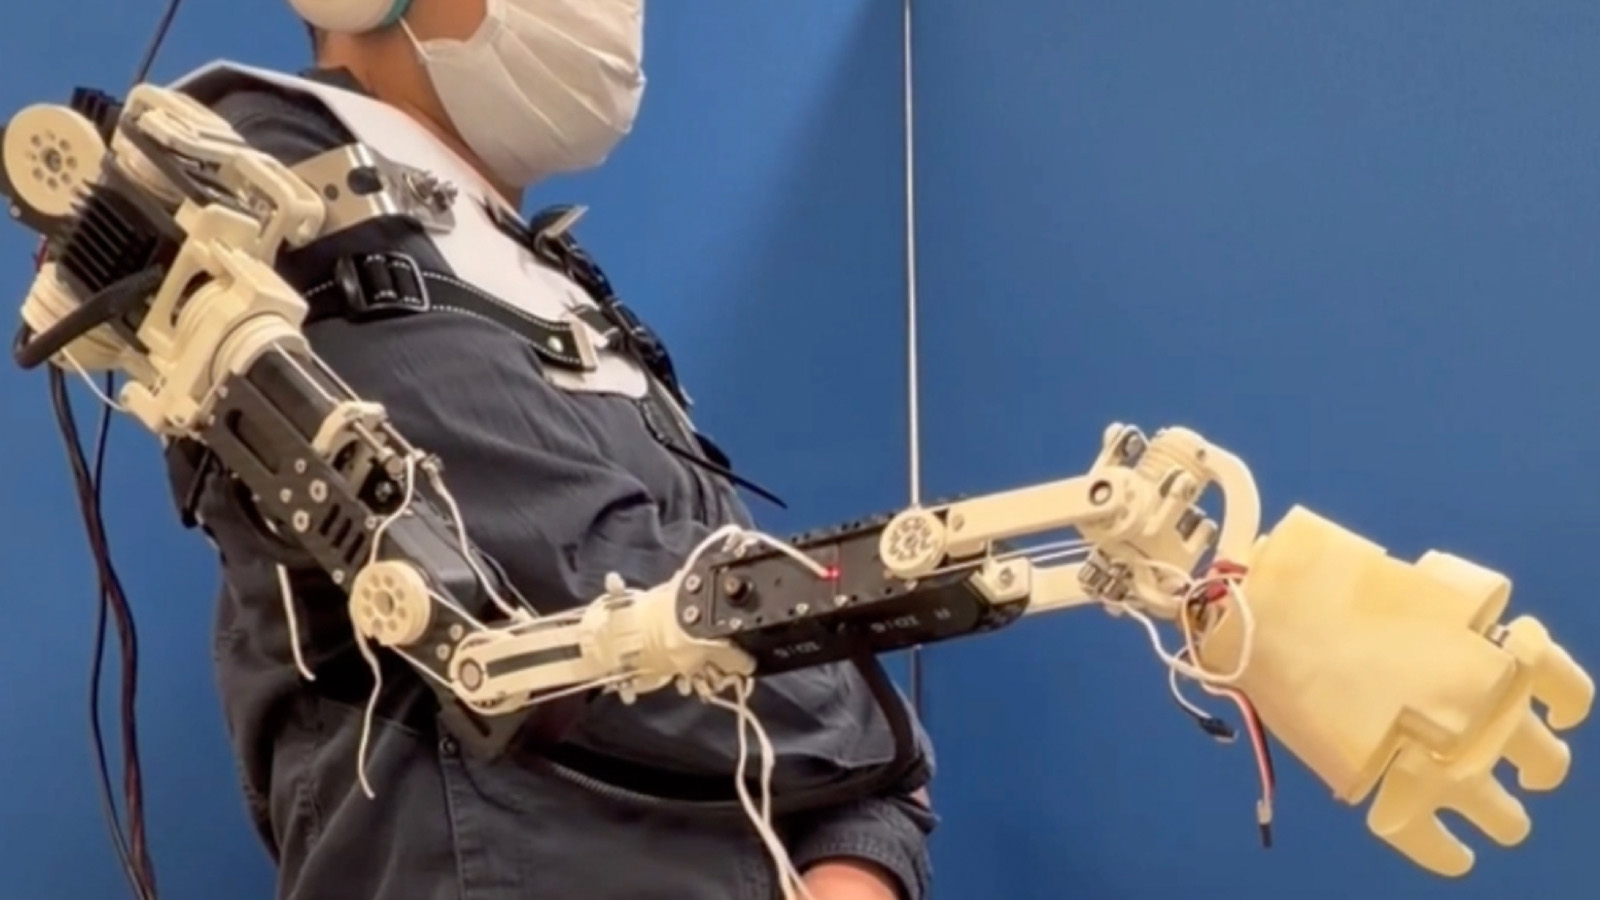
R&D of Electric Shoulder Prostheses
We develop myoelectric shoulder prostheses that reconstruct arm movements for people with shoulder disarticulation, covering robotic arms, hands, sensor systems, and control methods.
Current members: Shuting BAI (D) · Ryo TAKADA (M2) · Zhiguang YANG (M1)
Selected works: Togo et al., IEEE OJEMB, 2021, etc.
Learn more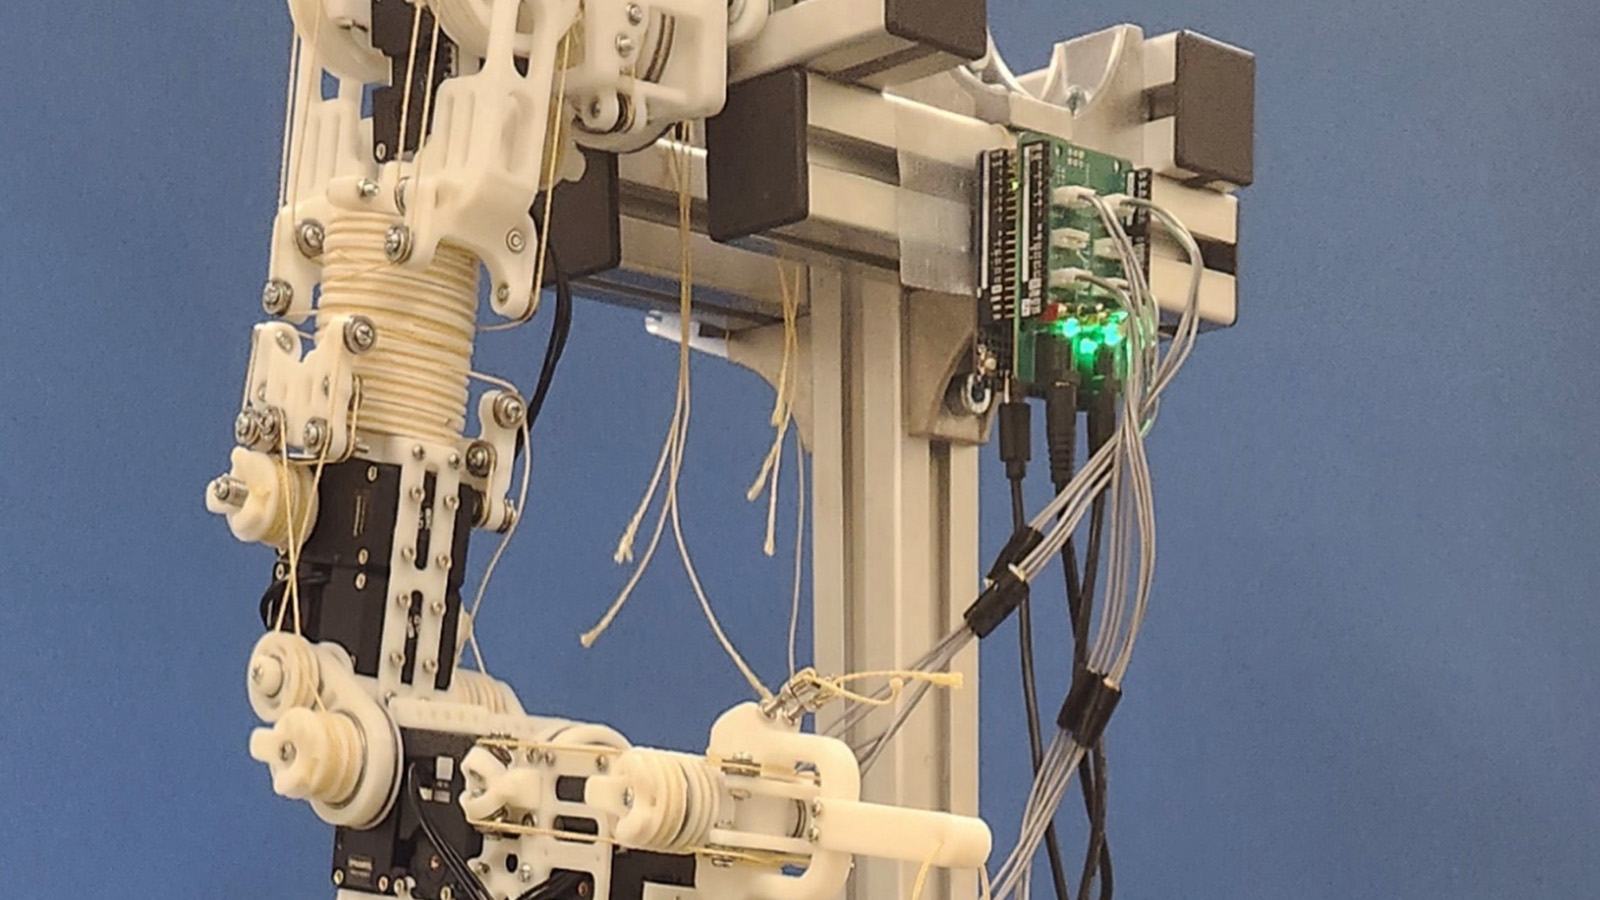
R&D of Fully Coupled Tendon-Driven Mechanisms
We develop the design theory and implementation of mechanisms in which every actuator output contributes to every joint, together with elemental technologies such as infinite wire-winding and gravity compensation mechanisms.
Current members: Hiroki SATO (M2) · Yuzhou LUO (M2) · Zewen LI (M1)
Selected works: Josef Neto et al., Mechatronics, 2026, etc.
Learn more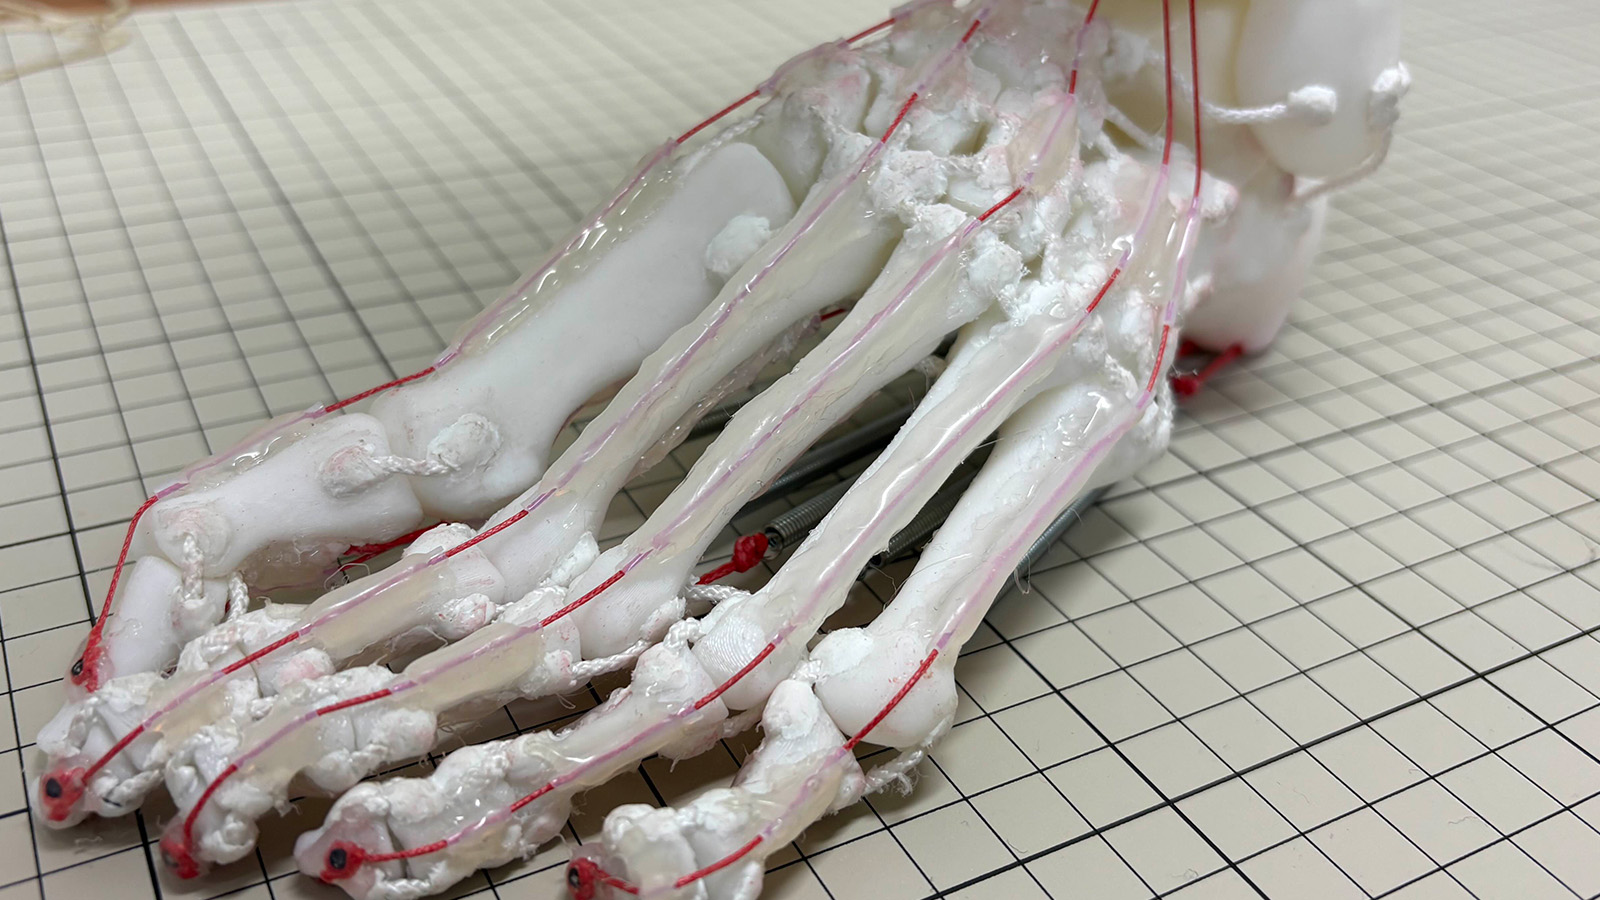
R&D of Anthropomimetic Foot and Leg
Using robots that mimic the skeletal and ligament structures of the human foot, we elucidate functions generated by foot morphology — such as shock absorption at landing and propulsion — and extend them to legged robots.
Current members: Kota HASHIMOTO (M1) · Kouki TAKEMURA (B4)
Selected works: Hashimoto et al., Bioinspiration & Biomimetics, 2026, etc.
Learn more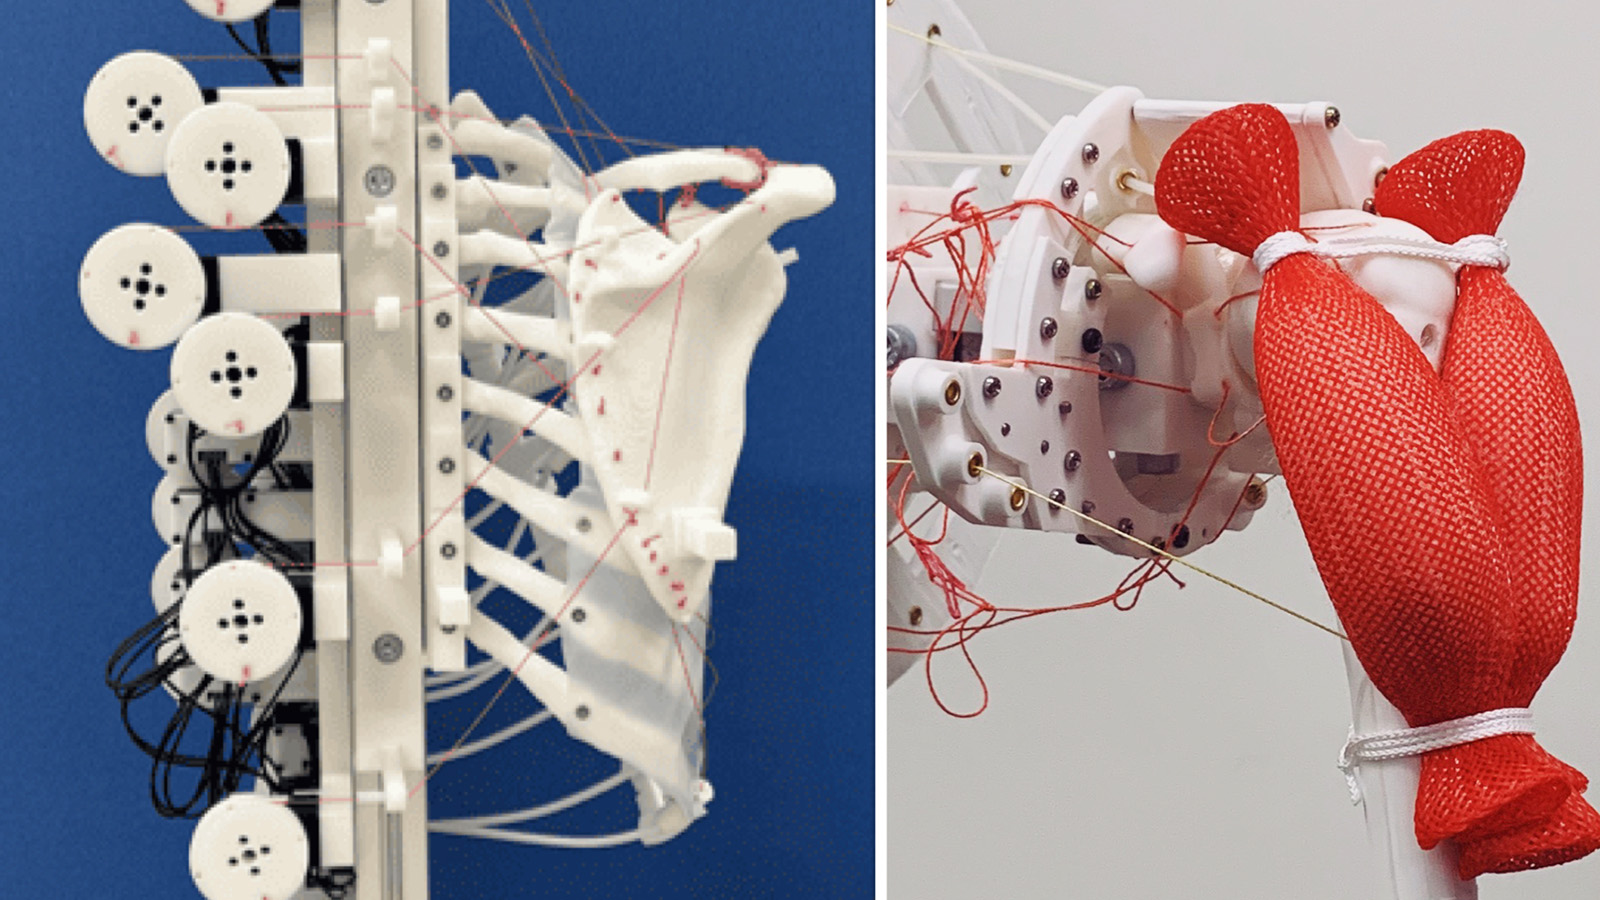
R&D of Anthropomimetic Shoulder Joints
Using robots that mimic the human glenohumeral and scapulothoracic joints, we investigate how the shoulder achieves both a wide range of motion and stability.
Current members: Koudai NAGASAWA (M2) · Tomohiro TAKEDA (M1)
Selected works: Nagasawa, ROBOMECH 2025, etc.
Learn morePast Projects
Past Projects
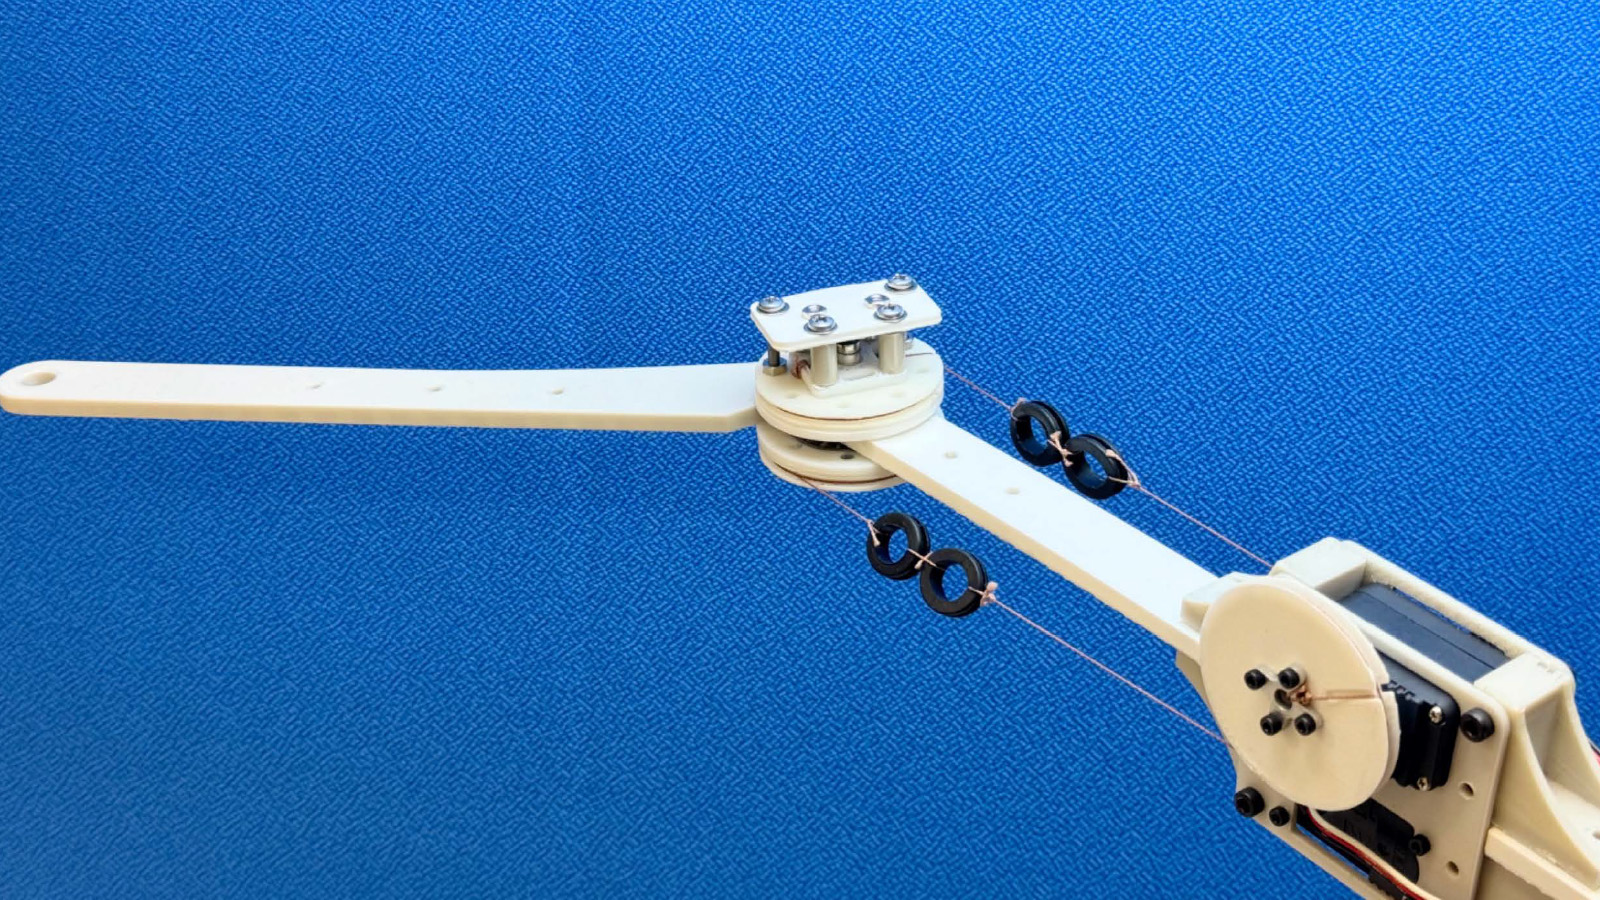
Virtual-Trajectory-Based Compliant Control
We developed compliant control for robots using the virtual trajectory — the time series of spring equilibrium positions — and demonstrated it on physical antagonistic-muscle robotic joints.
Status: Completed (FY2025)
Selected works: Umeda et al., IEEE Access, 2025, etc.
Learn more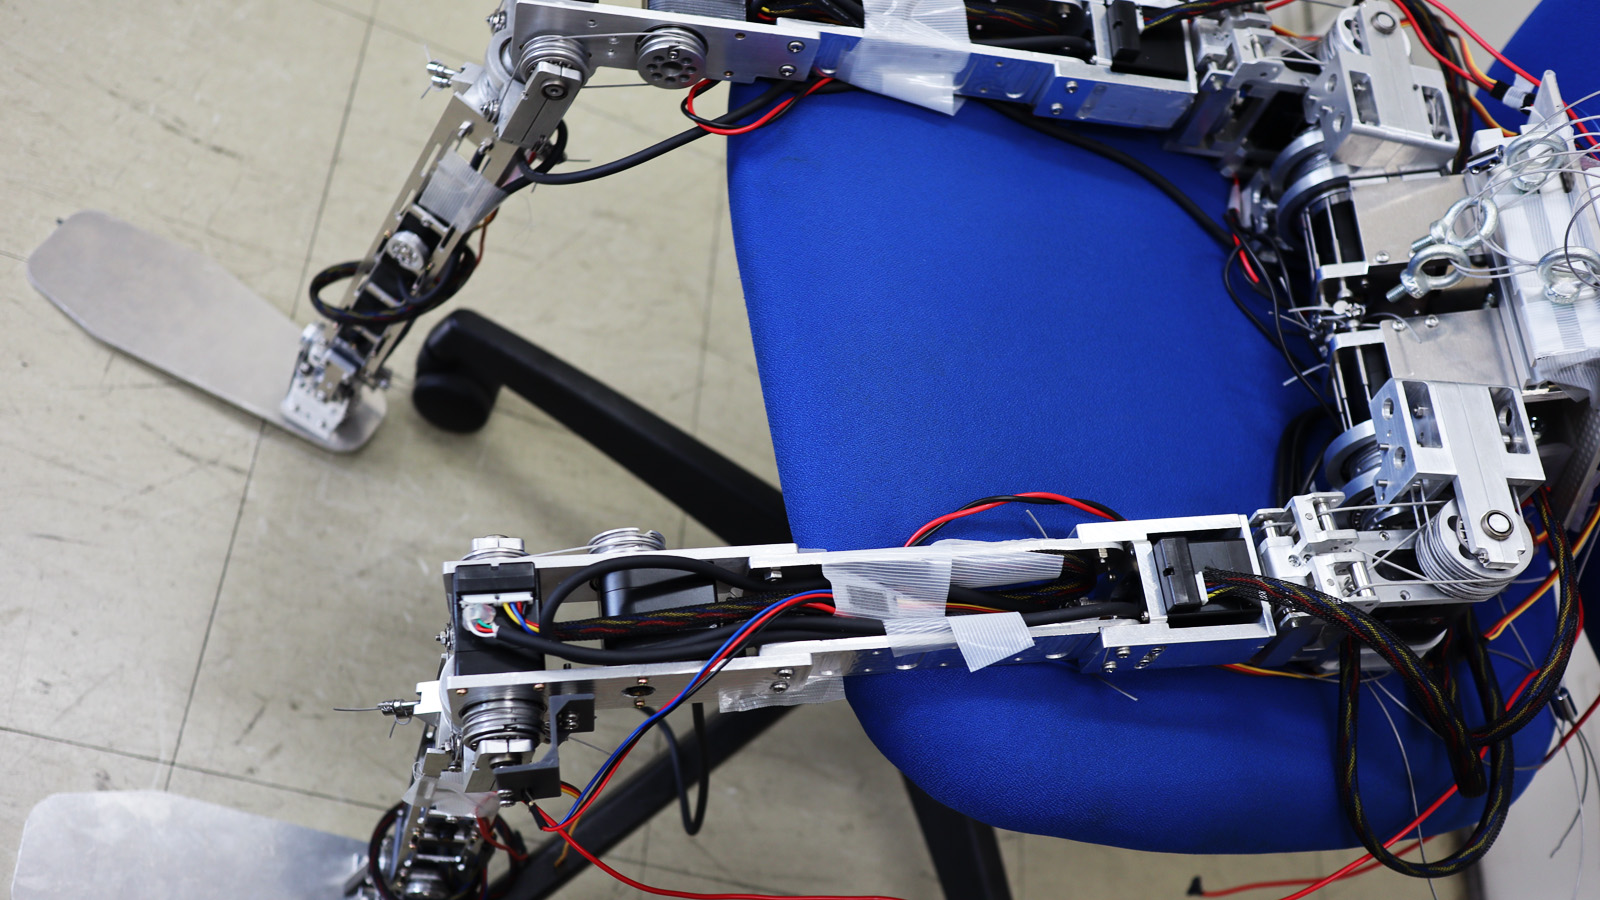
Coupled Tendon-Driven Bipedal Robot
We applied coupled tendon-driven mechanisms to legged robots and developed a bipedal robot combining robustness and compliance.
Status: Merged into the Anthropomimetic Foot and Leg project
Learn more