
Humanize Robotics
R&D of Anthropomimetic Foot and Leg
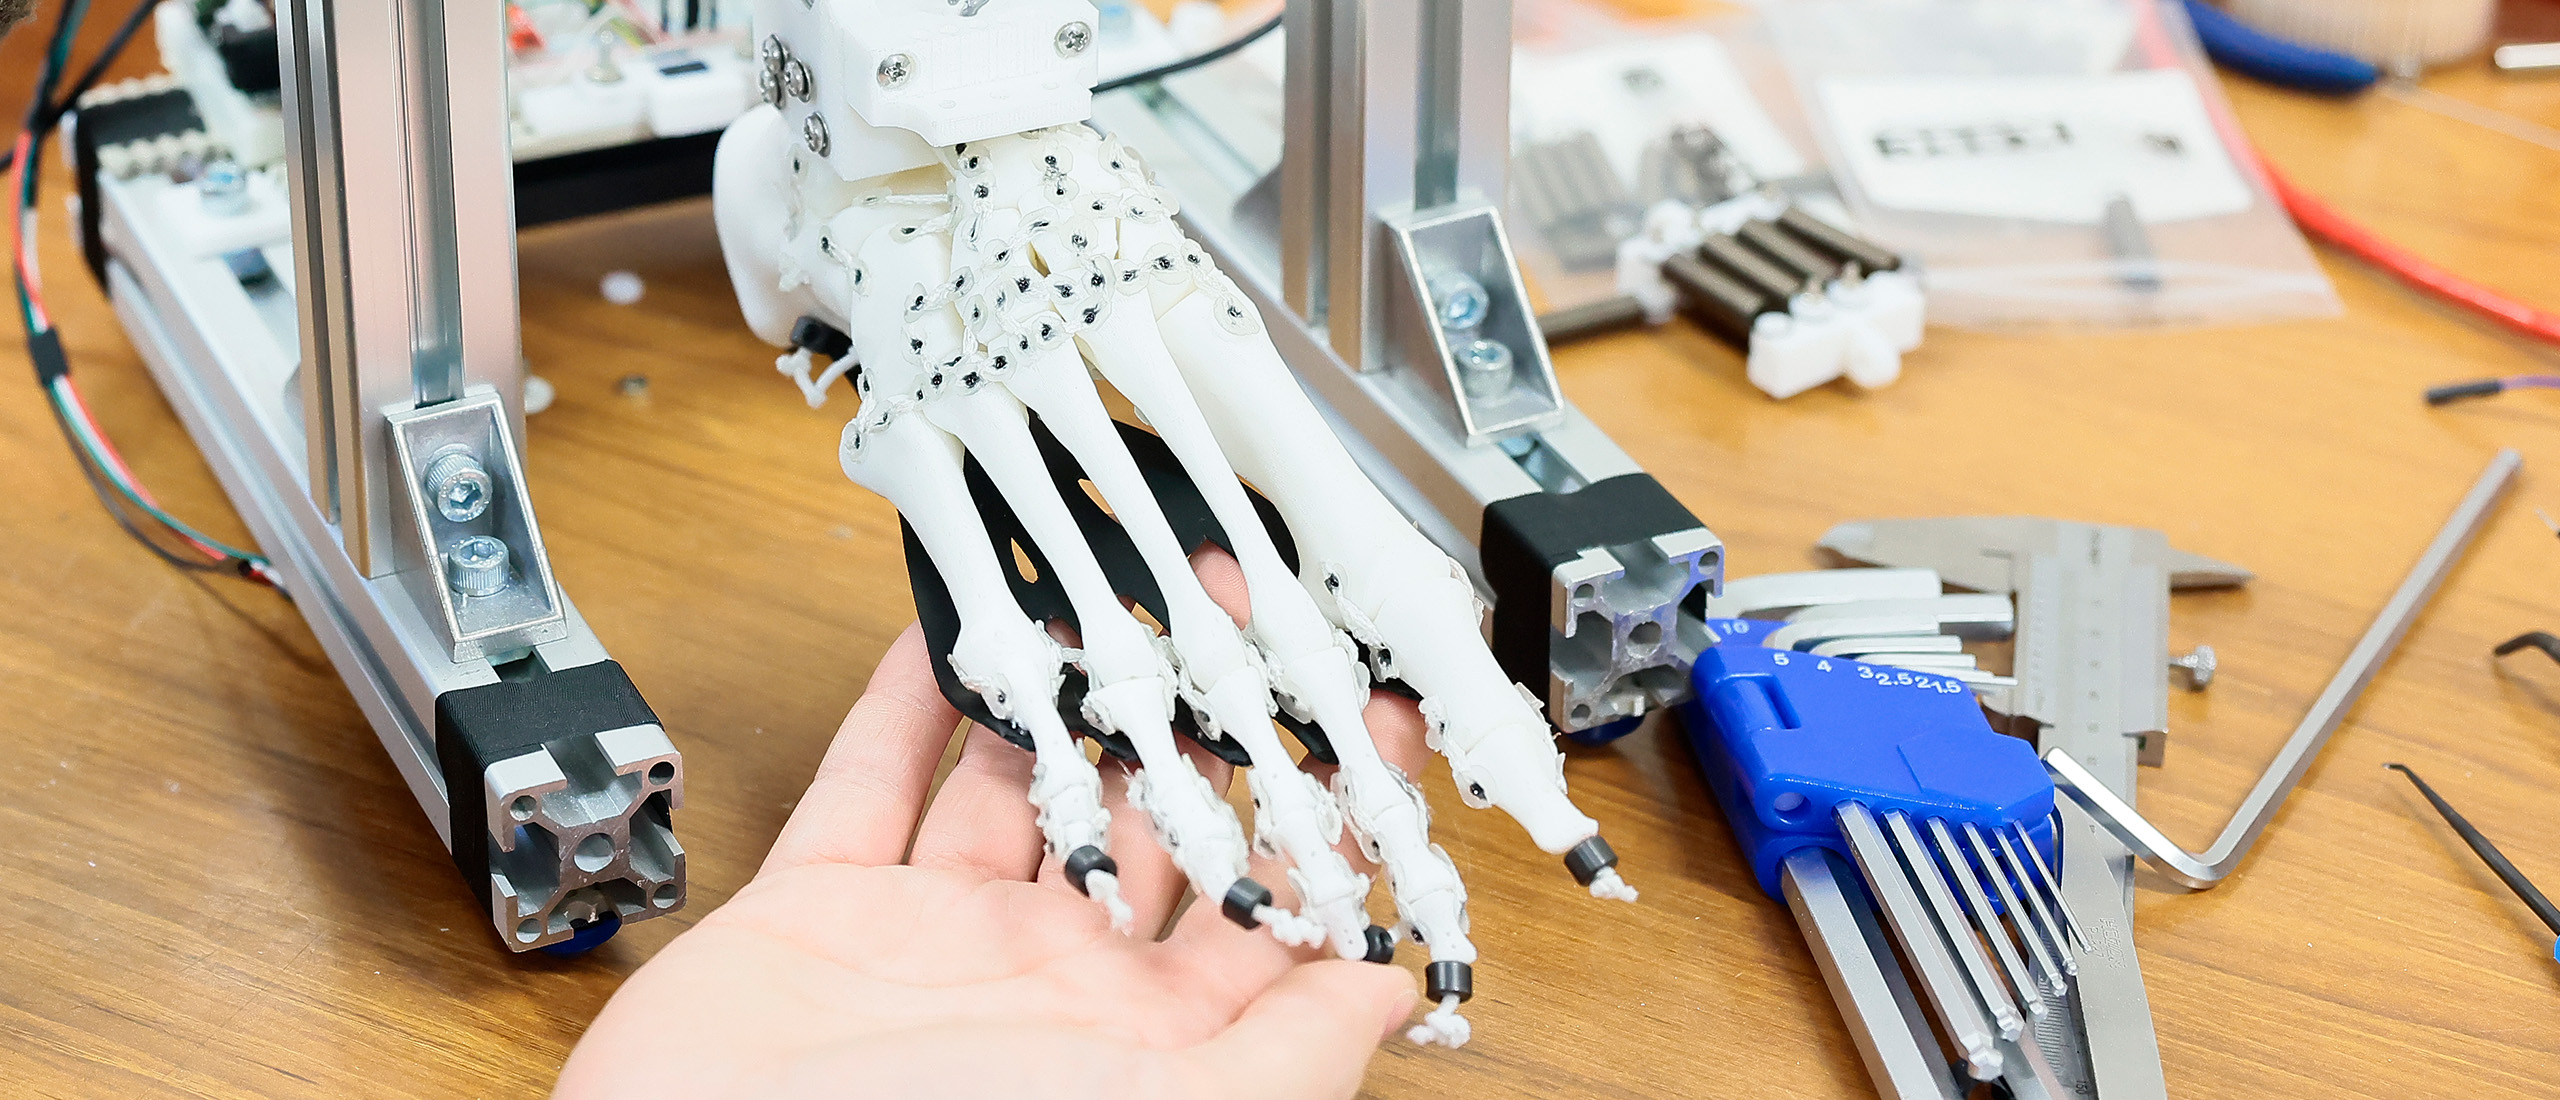
Using robots that mimic the skeletal and ligament structures of the human foot, we elucidate the functions generated by foot morphology — such as shock absorption at landing and generation of propulsion — and extend them to legged robots.
Current members: Kota HASHIMOTO (M1) · Kouki TAKEMURA (B4)
Anthropomimetic Foot
2021 – present
Overview
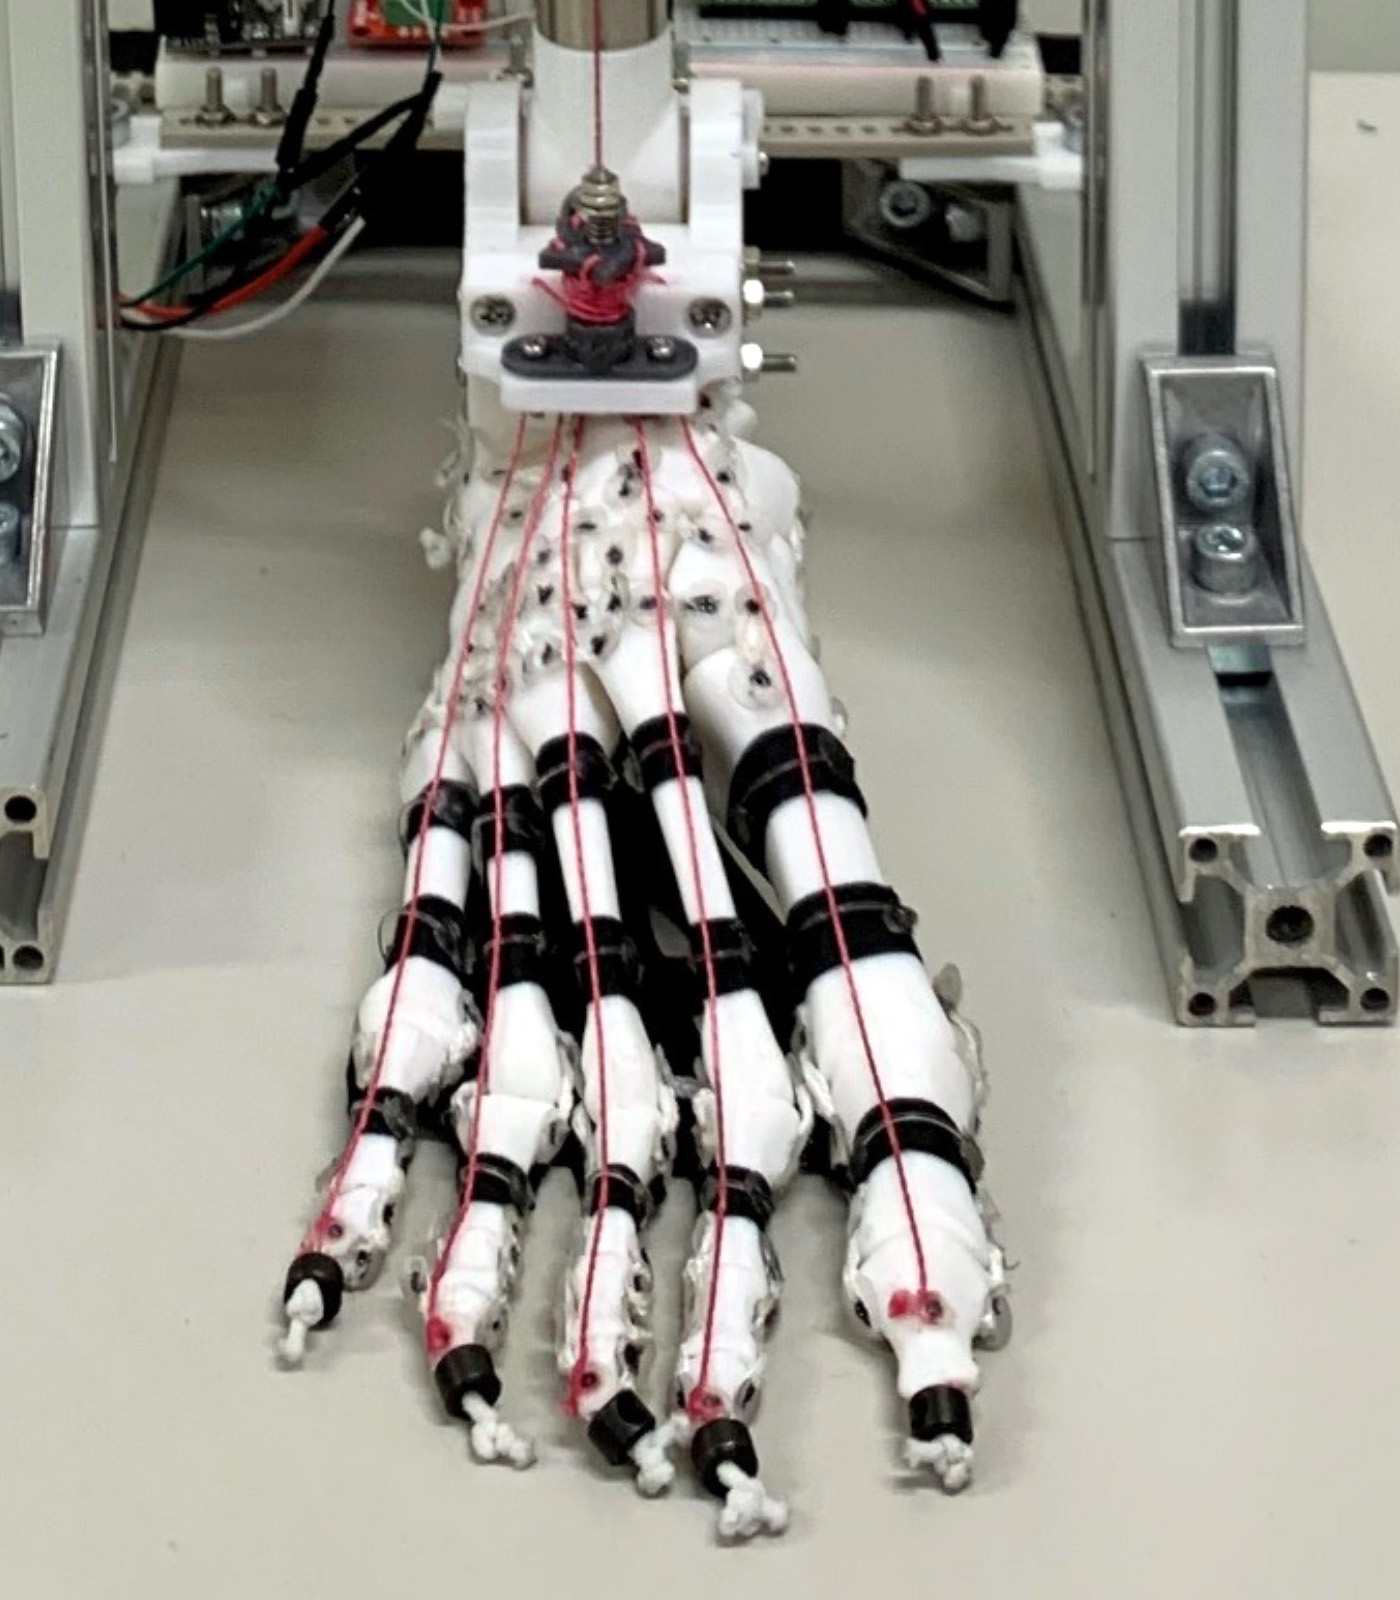
The human foot combines shock absorption at landing with the stiffness needed for push-off, thanks to its complex structure of many bones and ligaments. We build robots that mimic this structure and constructively elucidate the functions generated by foot morphology.
Technical Features
- Joints are formed by connecting bones based on human CT data (BodyParts3D) with ligament-type constraints
- Toe and heel postures can be changed by winding tendons
- Design data for the foot and the drop-test apparatus released as open source on GitHub
Specifications
- Scope: bones, ligaments, and plantar fascia of the foot
- Actuation: tendon-driven wires mimicking muscle arrangement
- Ligament fixation: welded-ligament method for higher load capacity
Results
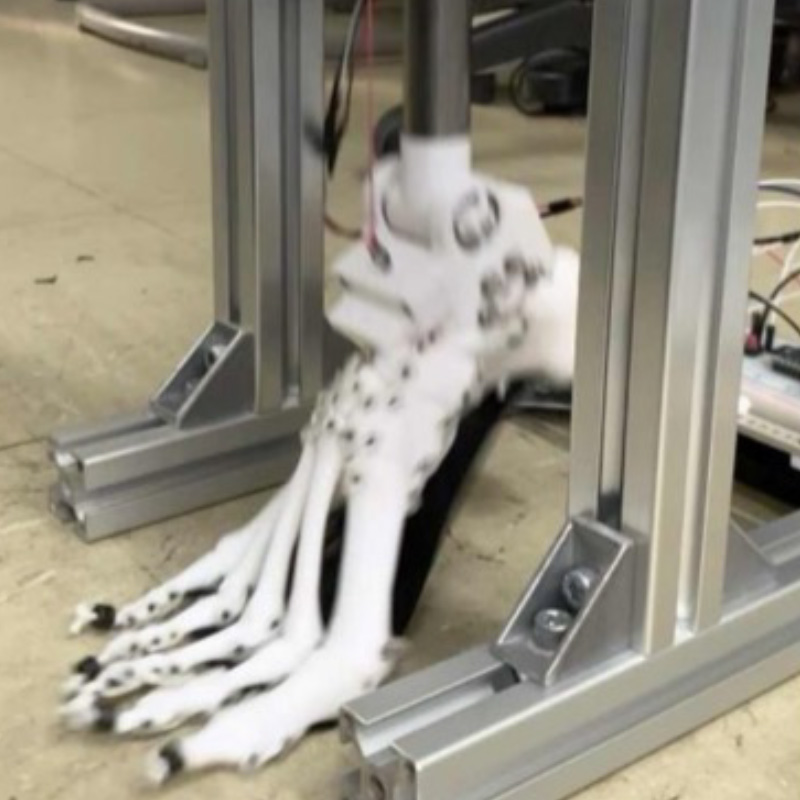
Revealed that the change in foot viscoelasticity at landing depends on morphology and posture
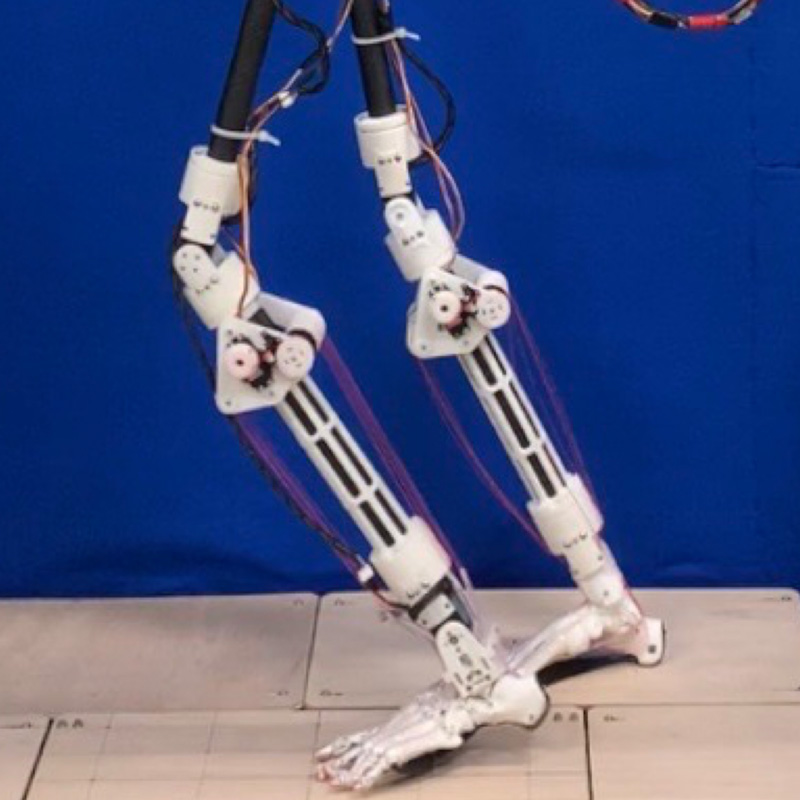
Applied the anthropomimetic foot to a planar-constrained bipedal walking apparatus
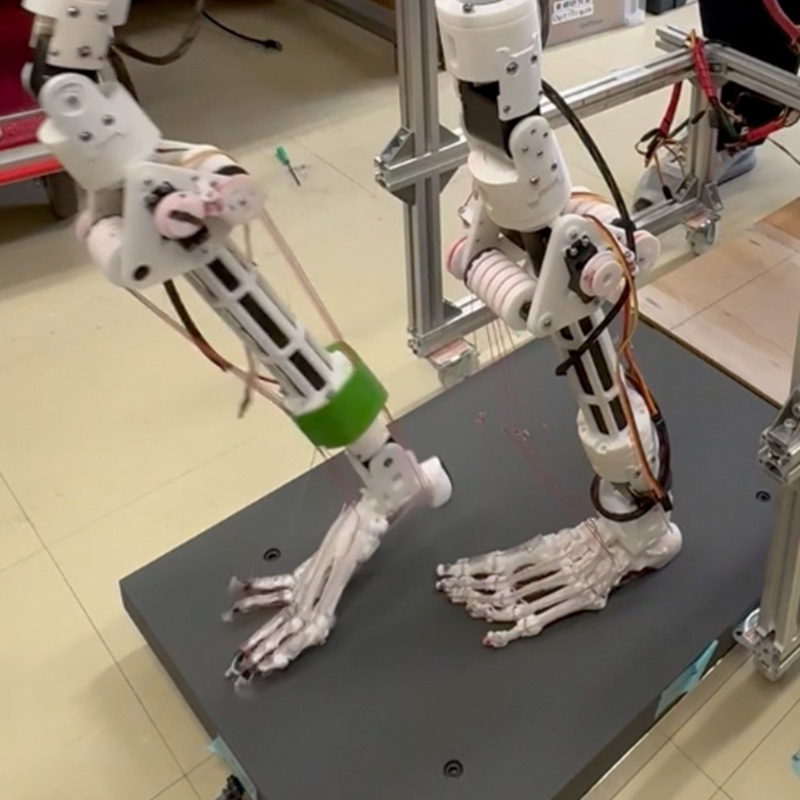
Measured the ground reaction force characteristics of the anthropomimetic foot
Related Videos (in Japanese)
2022年度 卒論 着地時における人体模倣足部の粘弾性変化に関する研究