
Humanize Robotics
R&D of Anthropomimetic Forearm and Hand
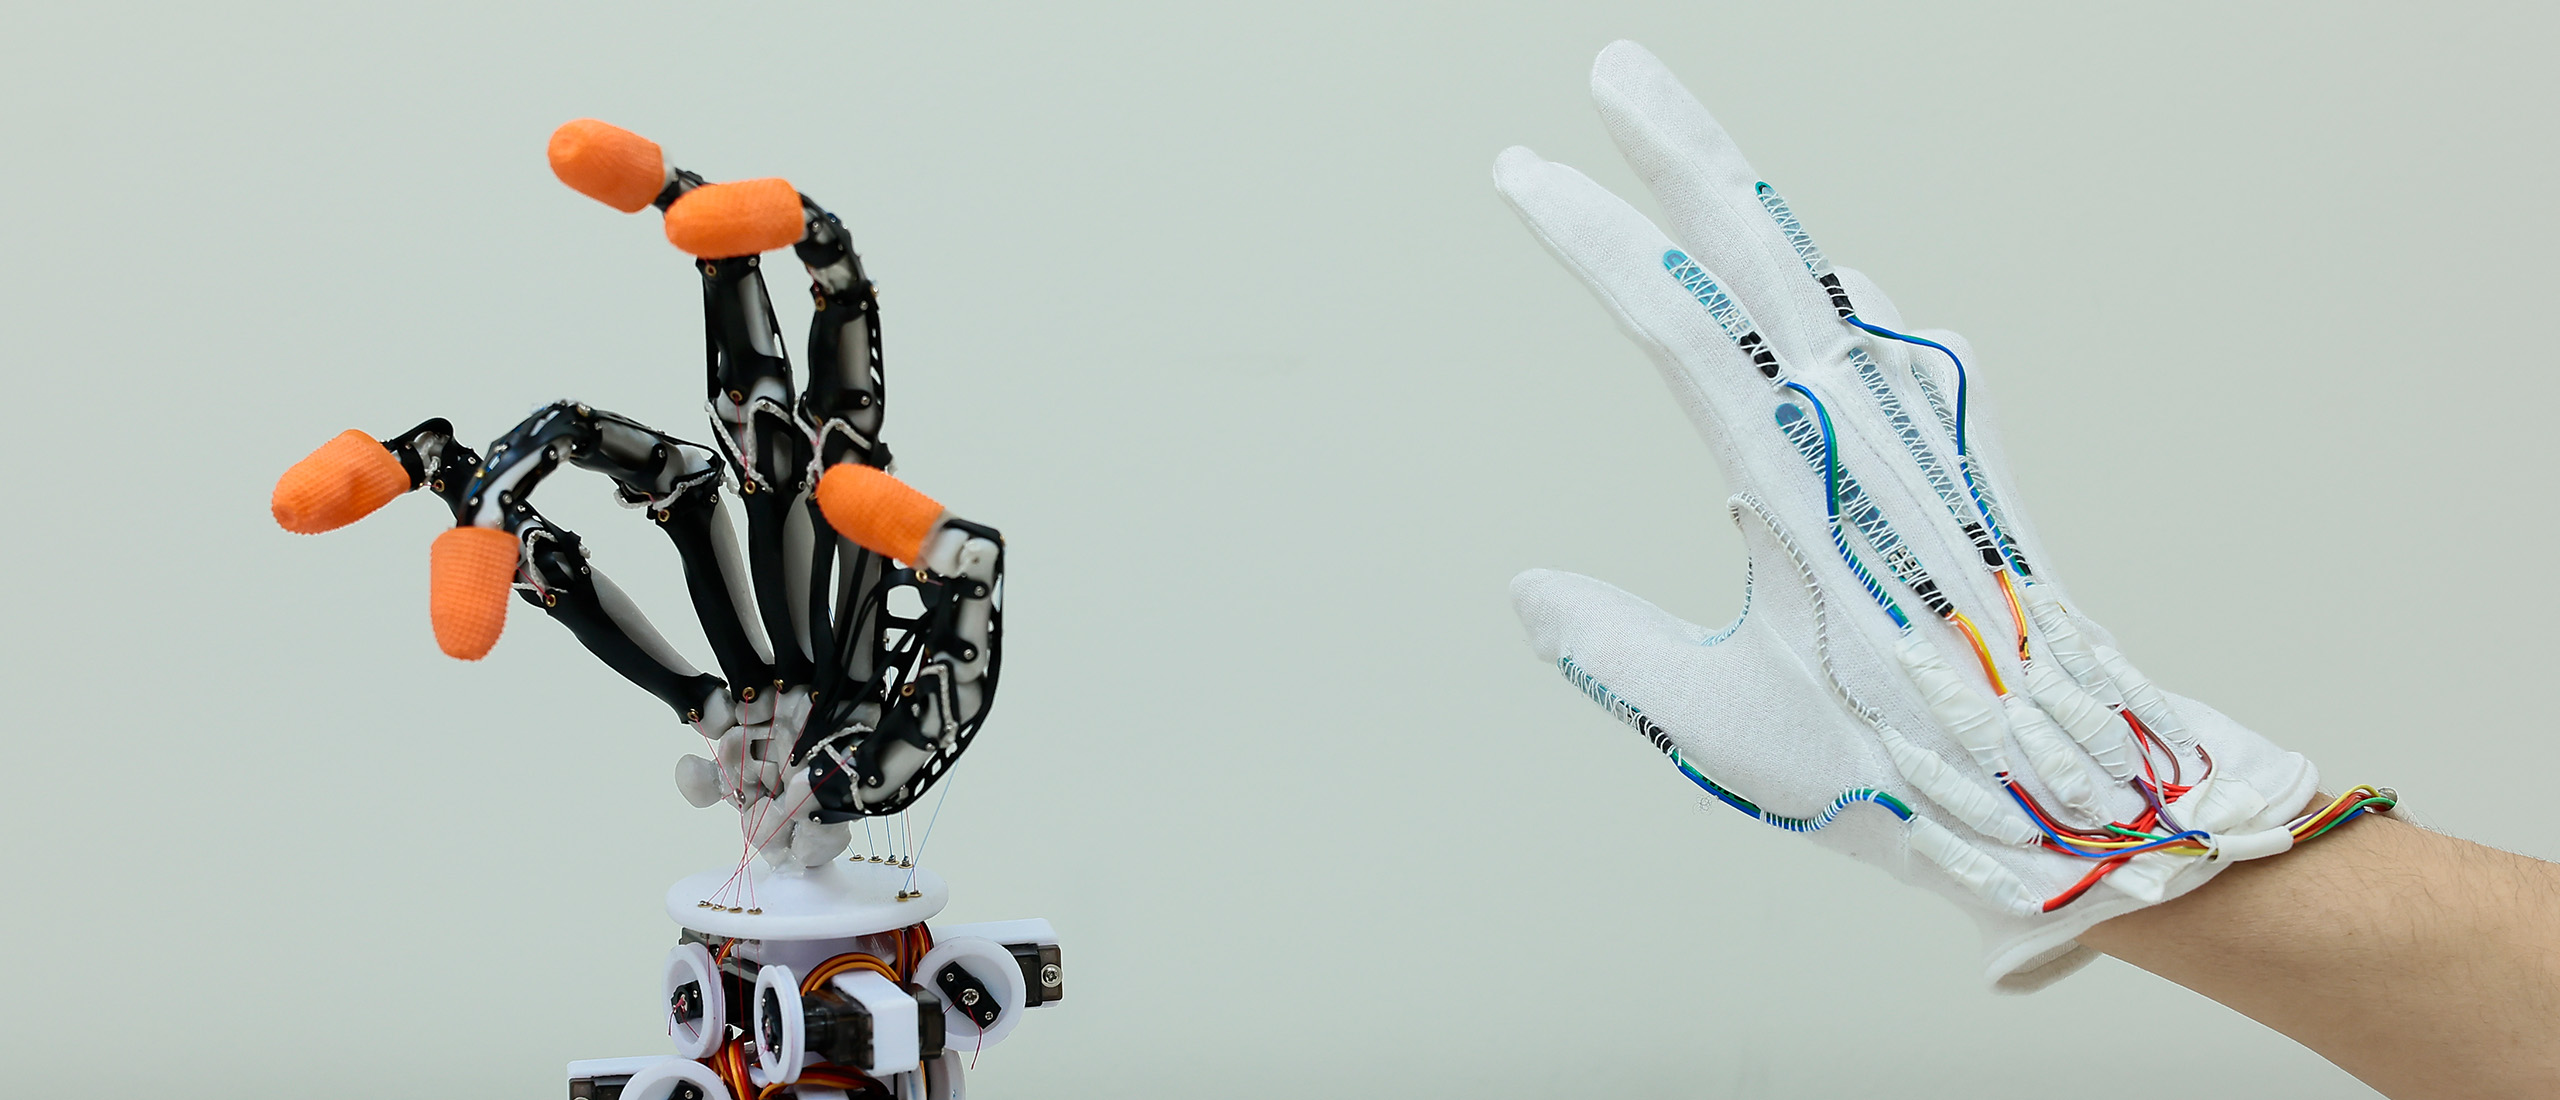
Human dexterity resides not only in the brain but also in the body itself — bones, muscles, tendons, and skin. We build robotic forearms and hands that faithfully mimic these structures to constructively investigate the mechanisms underlying the dexterity of the human hand.
Current members: Kouki NAKAMURA (M2) · Itta WATANABE (M1) · Kose KURIBAYASHI (B4) · Haru SHIMAMURA (B4)
Anthropomimetic Robotic Forearm
2022 – present
Overview
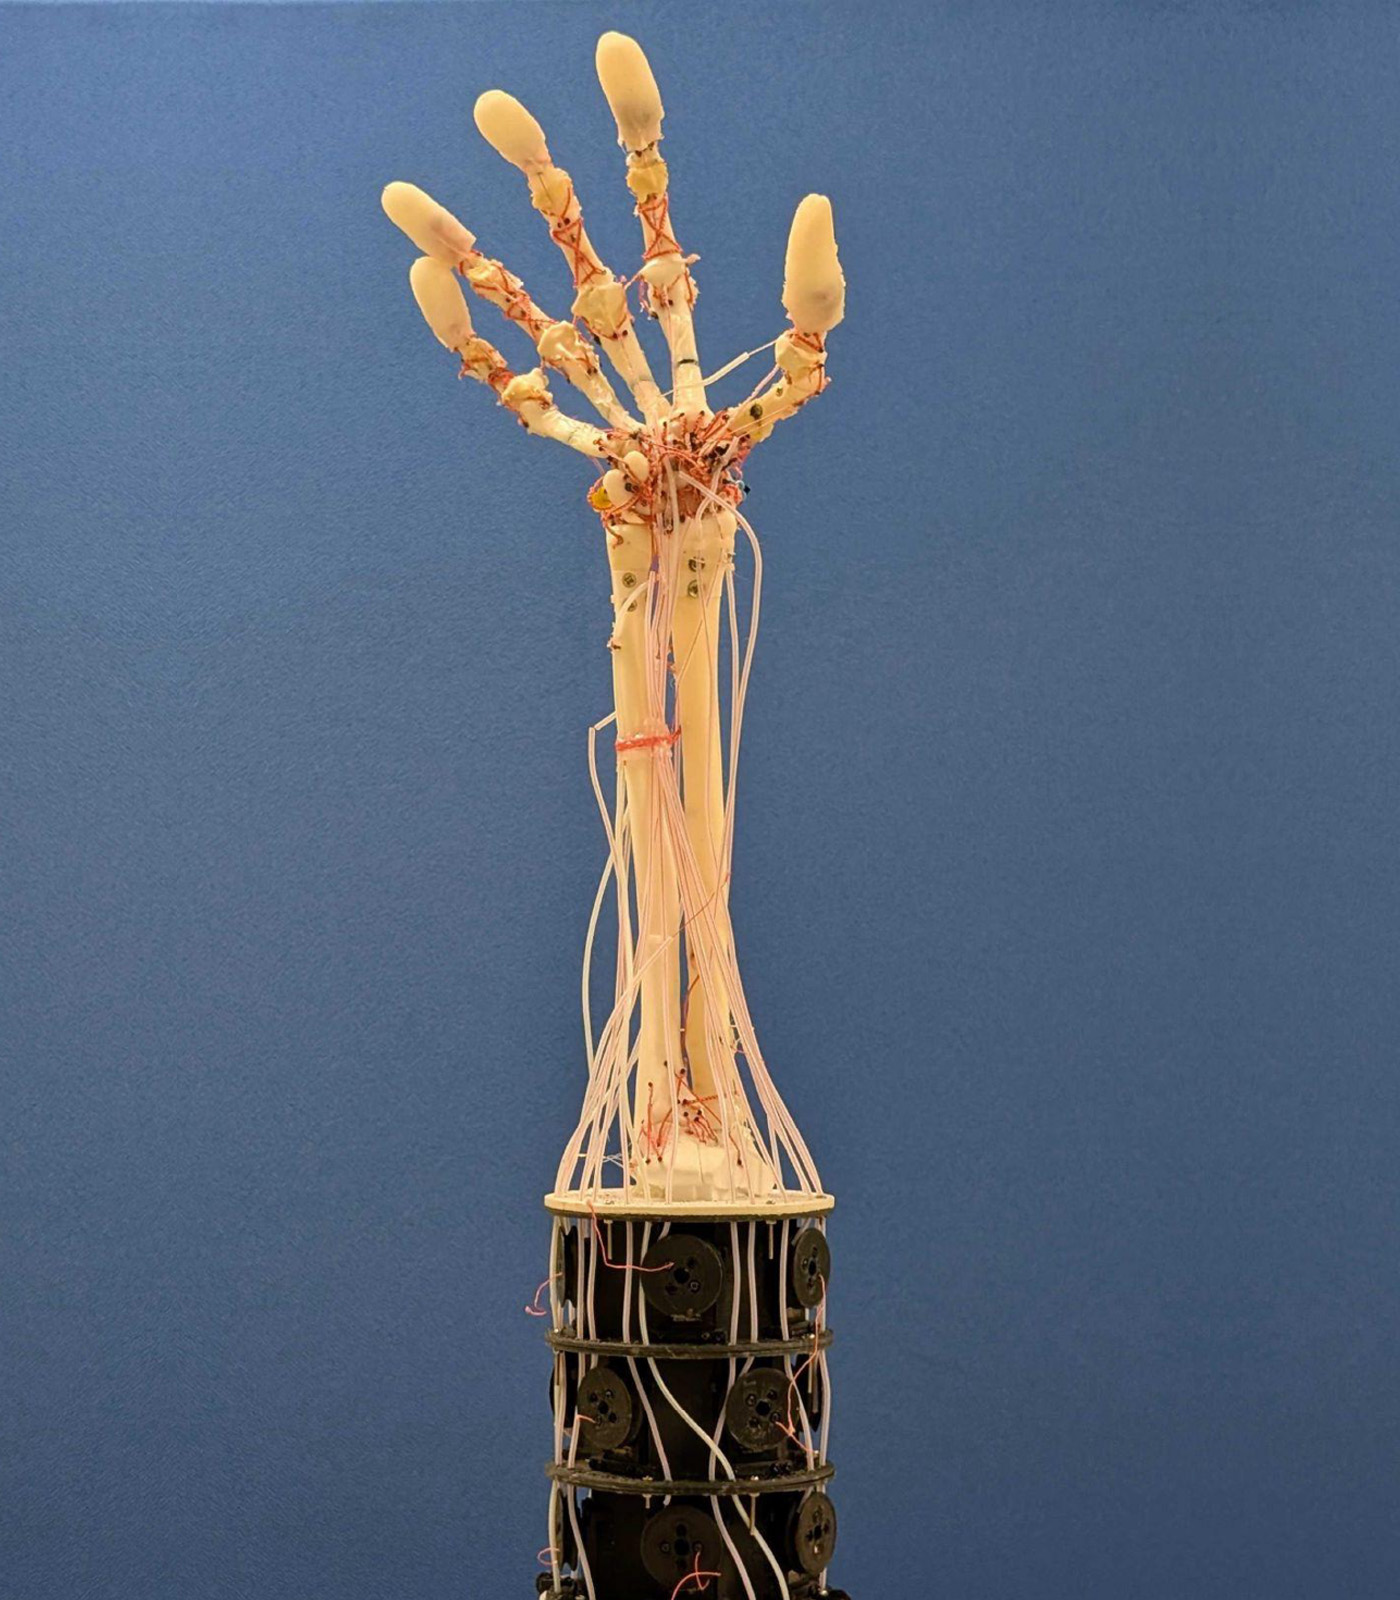
We build robots that mimic the skeletal, ligament, and tendon structures from the human forearm to the wrist, and constructively investigate how functions such as wrist stiffness anisotropy and joint viscoelasticity emerge from morphology.
Technical Features
- Joints are formed by connecting bones based on human CT data (BodyParts3D) with ligament-type constraints
- Two-layer elastic fingertips enable object grasping and wrist motion
- Reproduces the range of motion of the human wrist
Specifications
- Scope: bones and ligaments of the forearm, carpal bones, and fingers
- Actuation: tendon-driven wires mimicking 22 muscles
- Control: teaching playback
Results
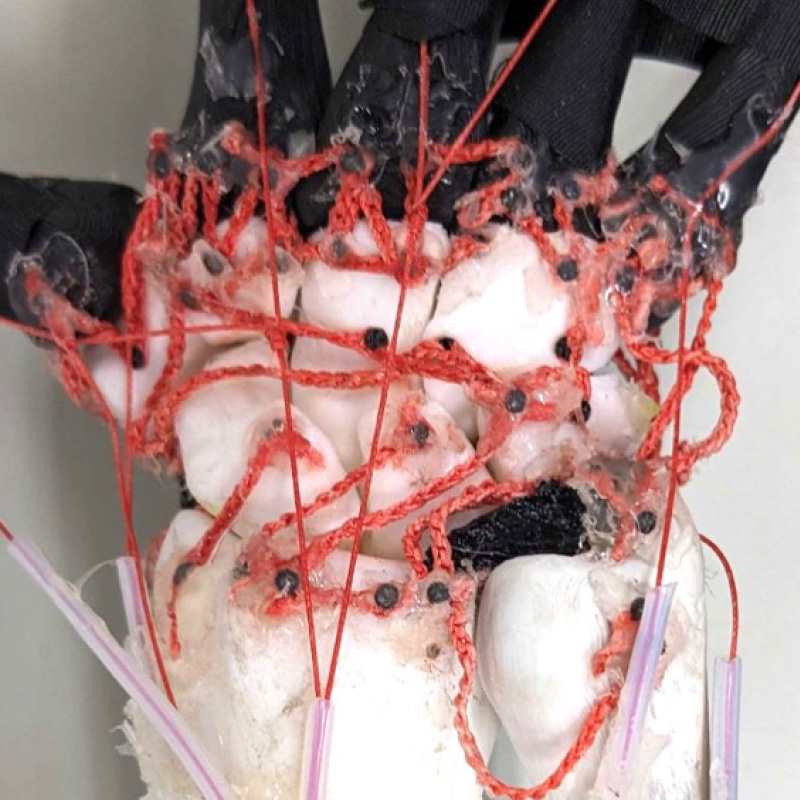
Developed a method to construct wrist joints by mimicking bones and ligaments
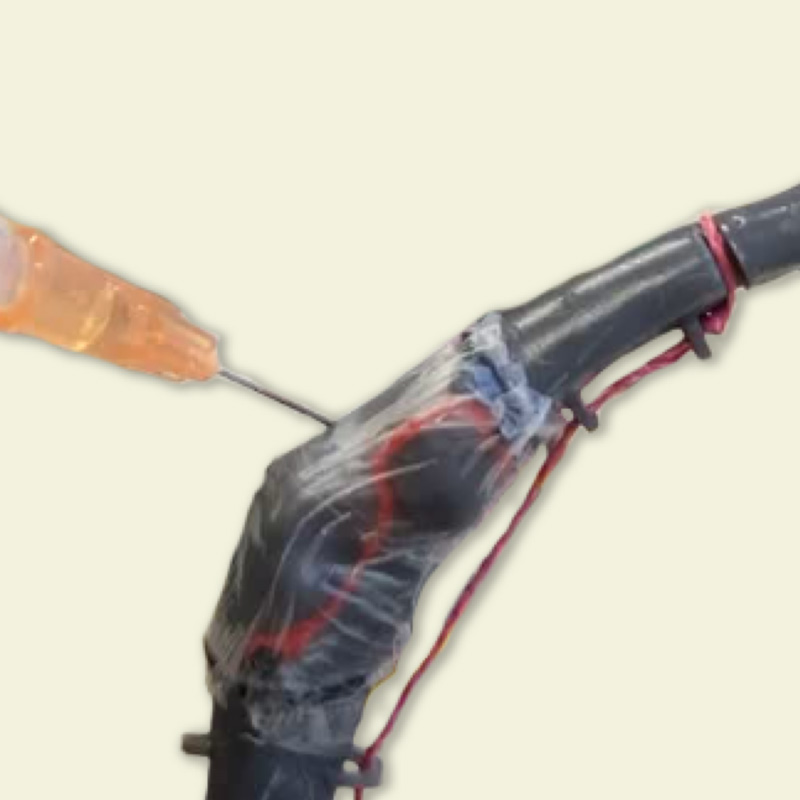
Developed finger joints with designable viscoelasticity by enclosing synovial-fluid-like liquid in the joint capsule
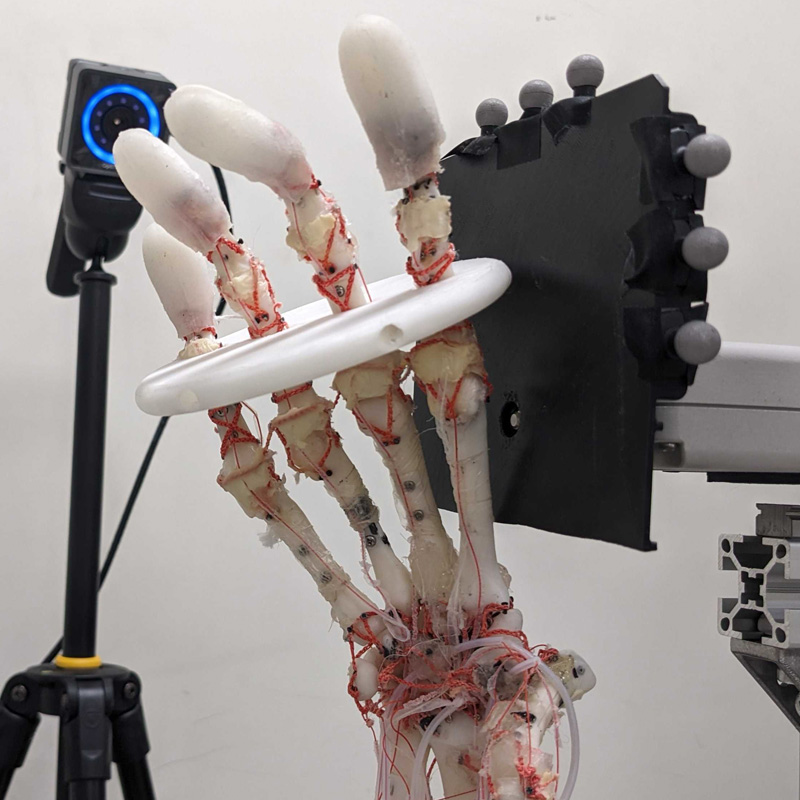
Revealed that carpal bone morphology generates the stiffness anisotropy of the wrist
Anthropomimetic Middle-Finger Robot Kit
2024 – present
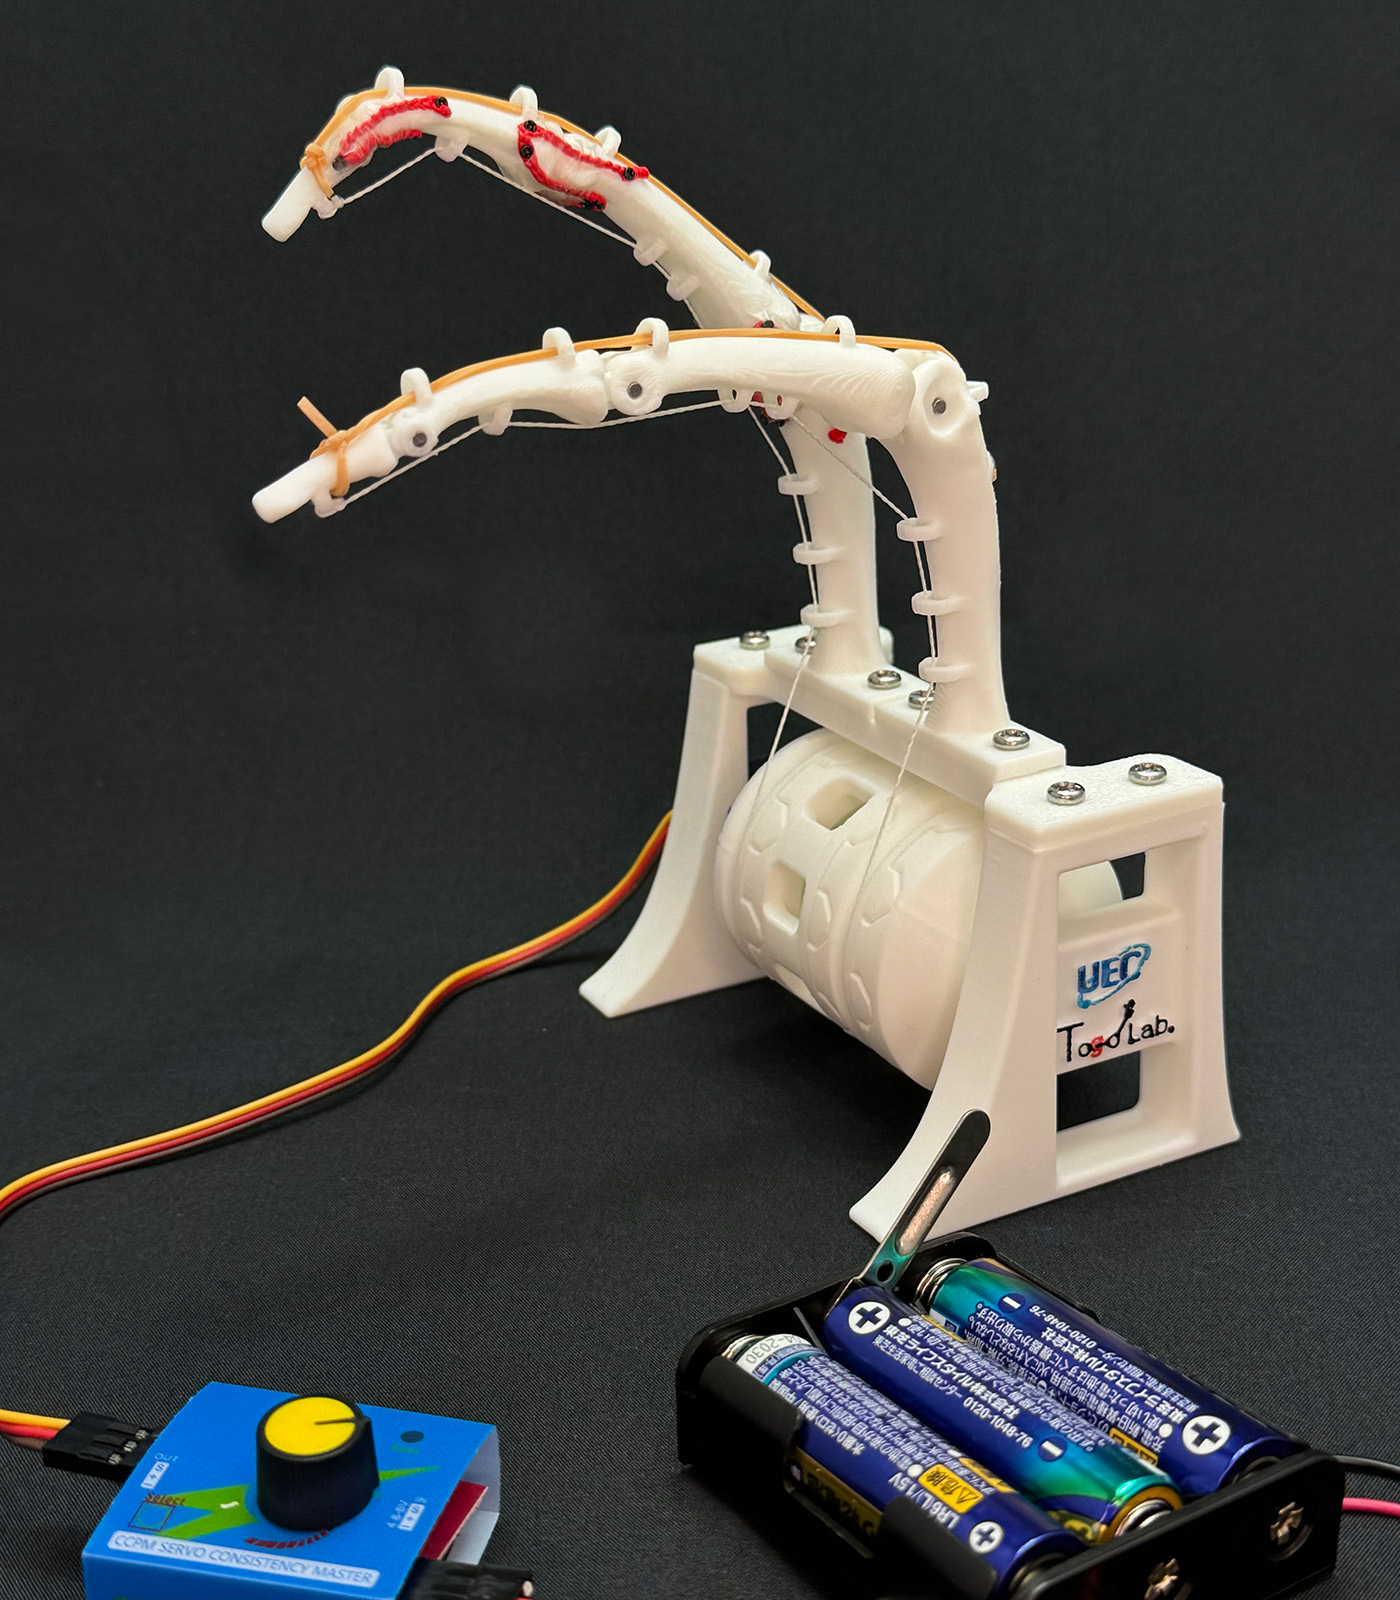
Overview
An educational kit version of our anthropomimetic middle-finger robot that anyone can assemble. Built from resin parts and wires, it lets learners experience the structure and motion principles of the human finger.
Technical Features
- Lets learners feel the difference between anthropomimetic joints and conventional robotic joints
- Design data released as open source on GitHub
- Inexpensive kit that participants assemble and take home at workshops
Specifications
- Subject: joints mimicking the bone and tendon structure of the human middle finger, plus a conventional axial robot joint
- Materials: resin parts, wires, and silicone
- Control: manual operation via a servo controller
Workshops
- Takumi Girl Project: summer lab experience at UEC (junior/senior high school girls)
- Takumi Girl Project: winter lab experience at UEC (junior/senior high school girls)
- Center for Neuroscience and Biomedical Engineering: Spring School (high school students)
- Togo Lab beginners’ workshop (new lab members)
Related Videos (in Japanese)
2020年度 卒論 人間機械協調系における補球動作の研究
2021年度 卒論 靭帯型拘束法を用いたワイヤ牽引転がり関節に関する研究
Recreation of HBA hand (HBAハンドの再現)
2022年度 卒論 人体の関節における液体潤滑を模倣した指関節構造の開発
2022年度 修論 ヒトの指比が把持性能に与える影響に関する研究
2023年度 卒論 弾性生地の埋め込みによる人工皮膚の耐裂性の向上に関する研究
2024年度 修論 人体を模倣した流体潤滑を有する指関節構造の研究
2025年度 修論 冷却機能を備えた⼈⼯⽪膚の開発に関する研究
Related Publications
Journal Papers
Suzuka Higashijima, Yinlai Jiang, Hiroshi Yokoi, Shunta Togo, "Classification of human grasping posture suitable for catching and its application to robotic hand," Journal of the Society of Biomechanisms, Vol. 47, No. 1, pp. 54–62, 2023.
International Conference Papers
Yoshinobu Obata, Yinlai Jiang, Hiroshi Yokoi and Shunta Togo, “Design of anthropomimetic robotic wrist joint and forearm,” 2023 IEEE International Conference on Systems, Man, and Cybernetics (SMC), pp. 1766–1771, Oahu, Hawaii, USA, Oct. 1-4, 2023.