
Humanize Robotics
R&D of Anthropomimetic Shoulder Joints
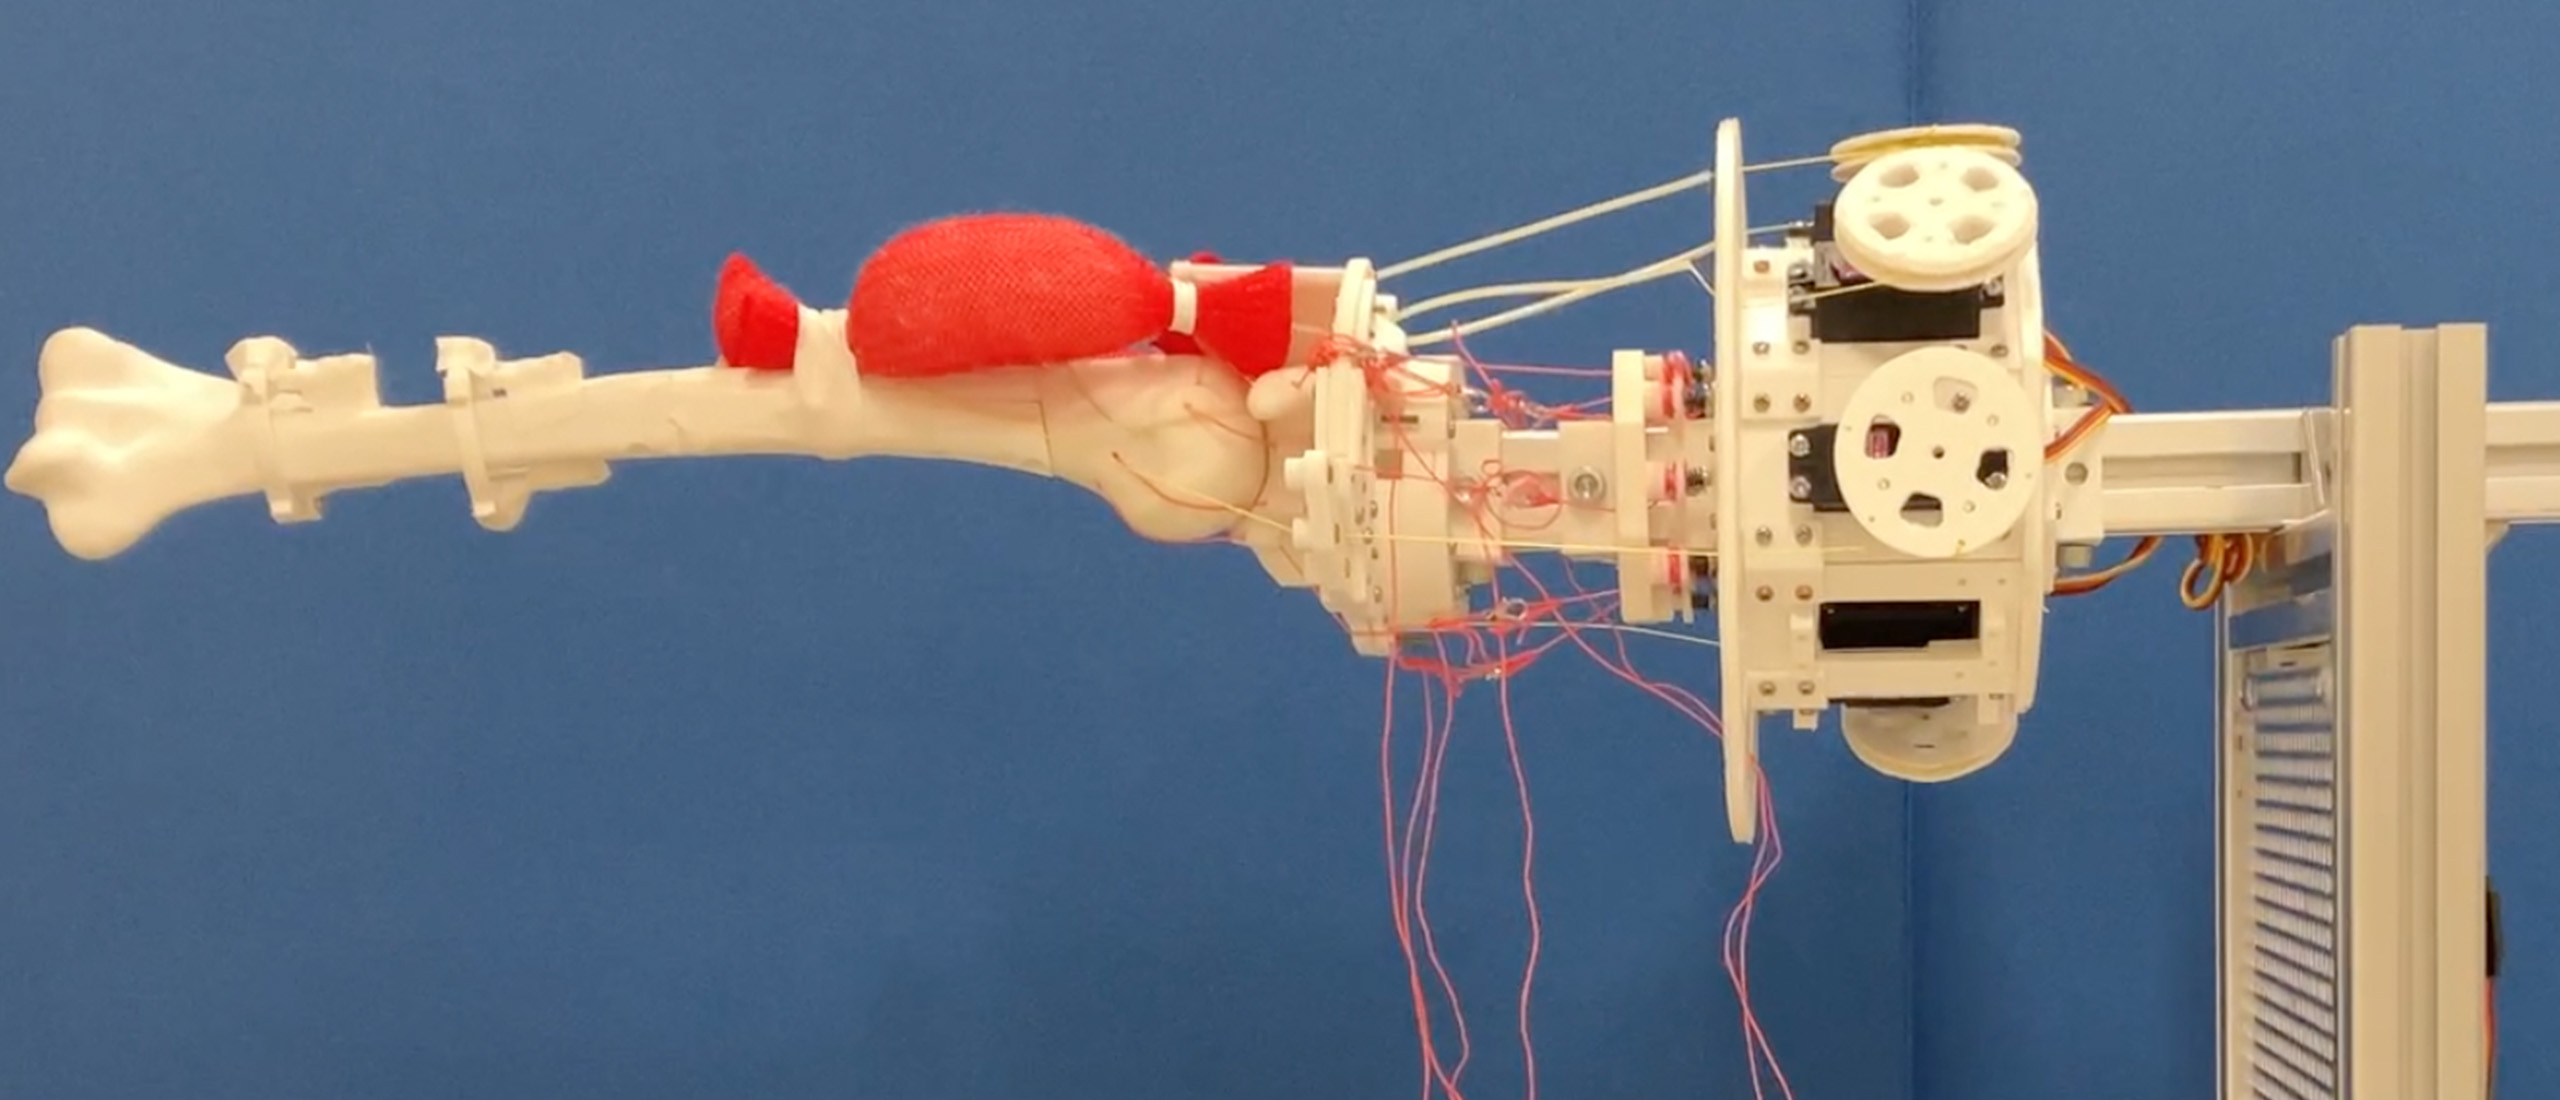
Using robots that mimic the structures of the human glenohumeral and scapulothoracic joints, we investigate how the shoulder achieves both a wide range of motion and stability.
Current members: Koudai NAGASAWA (M2) · Tomohiro TAKEDA (M1)
Anthropomimetic Glenohumeral Joint
2023 – present
Overview
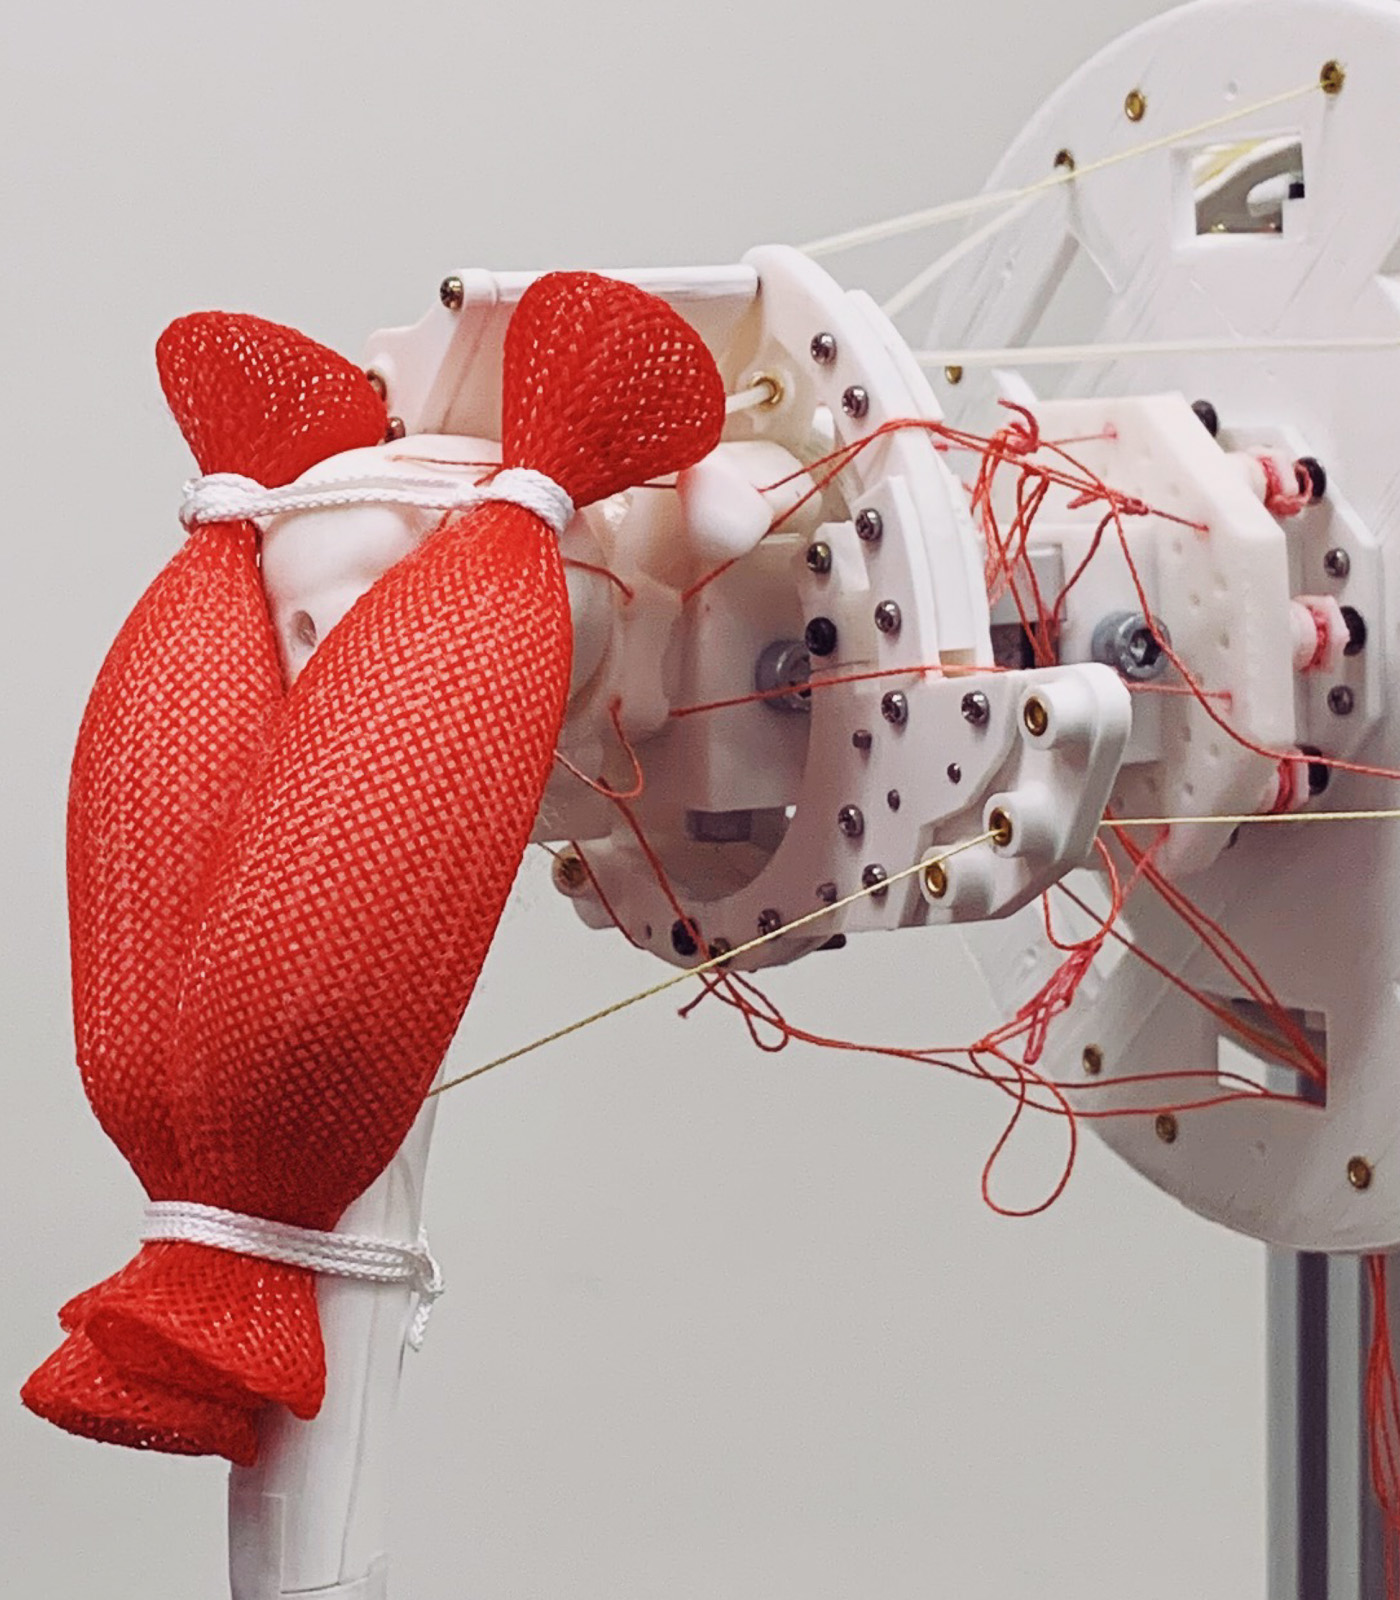
The human glenohumeral joint achieves both a wide range of motion and dislocation-free stability under the constraints of ligaments and tendons. We build robots that mimic this structure to investigate how both are achieved, and are extending the scope to the scapulothoracic joint.
Technical Features
- Reproduction of the glenohumeral joint with ligament constraints
- Tendon-driven wires mimicking muscle arrangement
- Extension to the shoulder complex including the scapulothoracic joint
Specifications
- Scope: glenohumeral and scapulothoracic joints (ligament and tendon constraints)
- Actuation: tendon-driven wires mimicking 11 muscles
- Control: teaching playback
Results
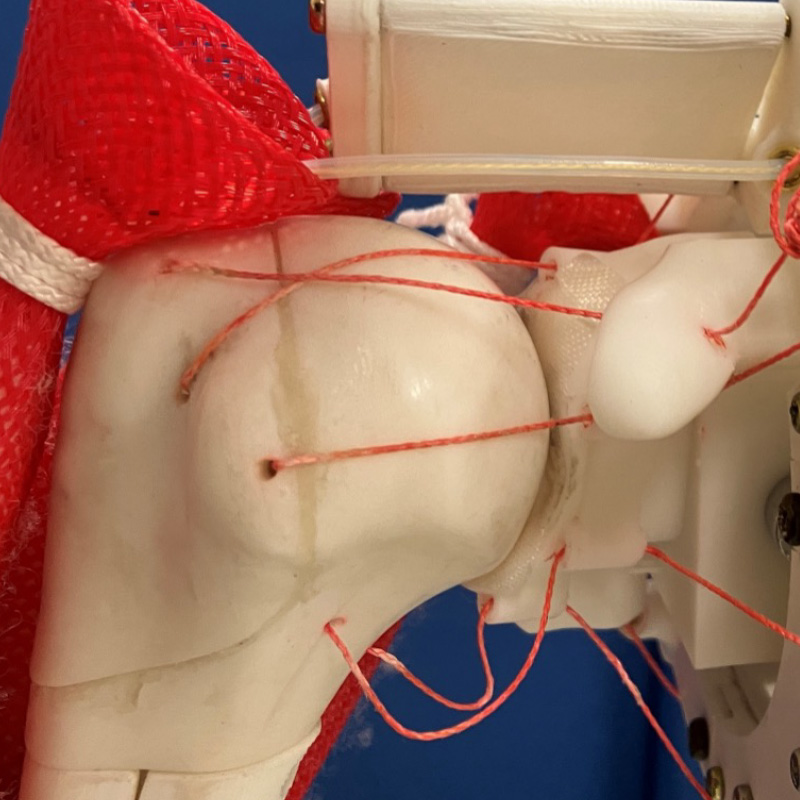
Developed a ligament-constrained anthropomimetic glenohumeral joint
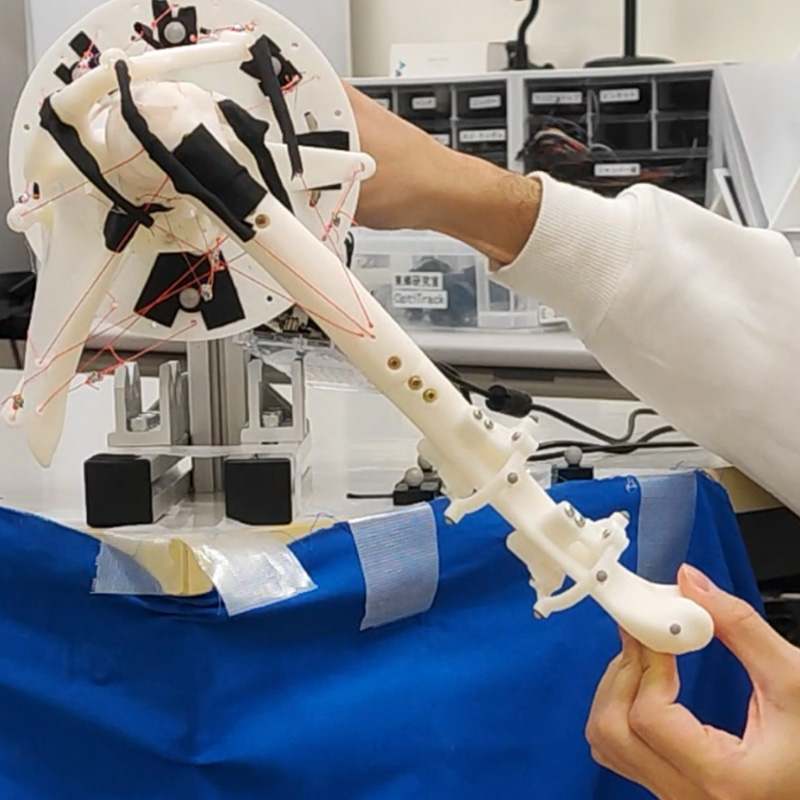
Applied the teaching-playback method
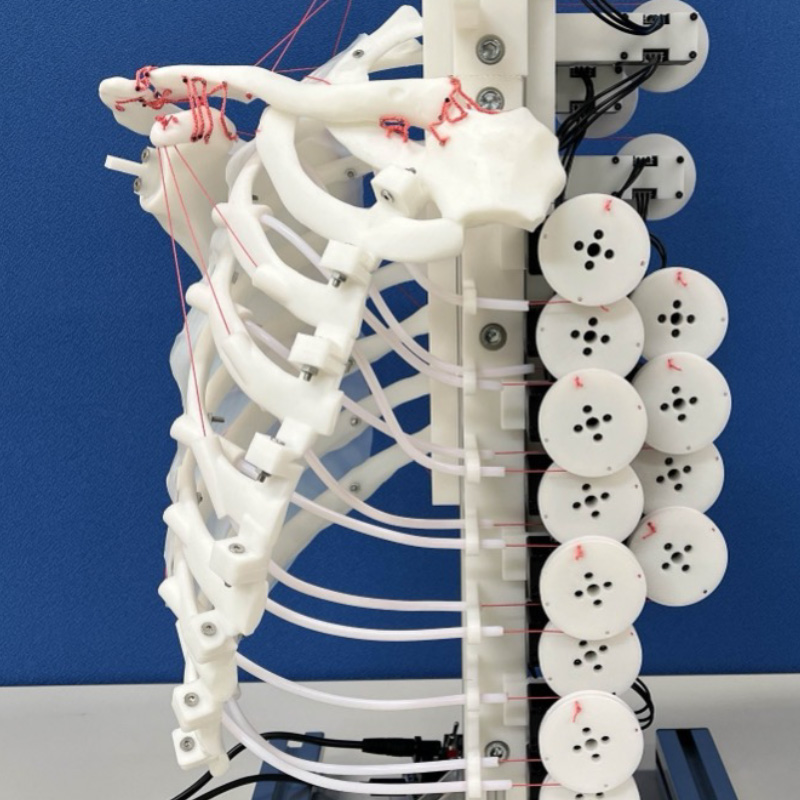
Developed an anthropomimetic scapulothoracic joint
Related Videos (in Japanese)
2023年度 修論 靭帯及び腱で拘束した人体模倣肩関節機構に関する研究