
Robotics
R&D of a Coupled Tendon-Driven Bipedal Robot
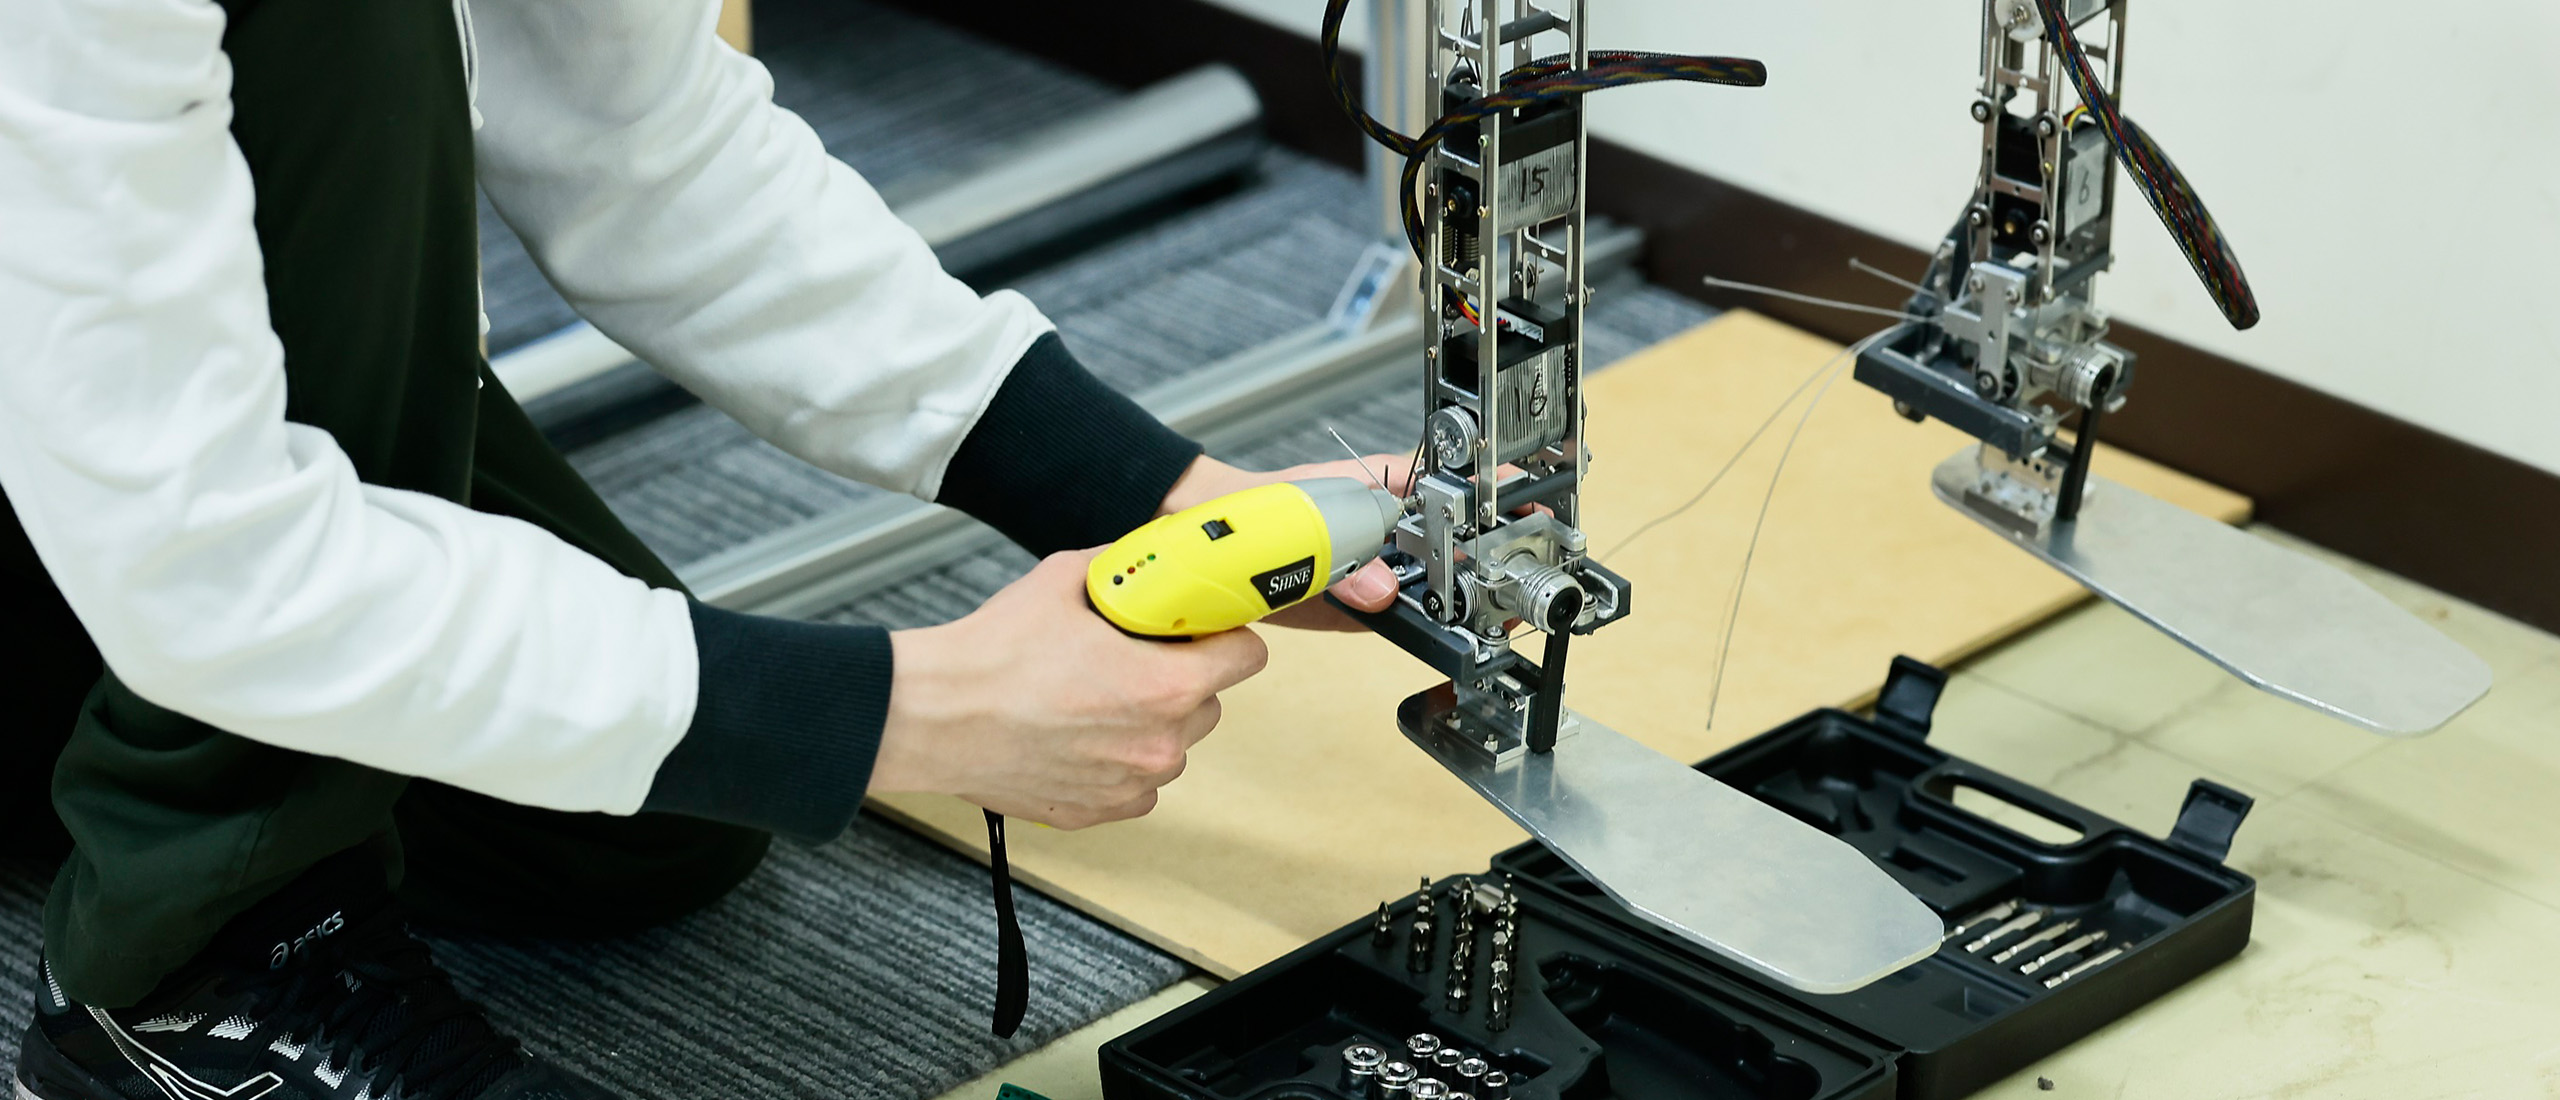
We applied coupled tendon-driven mechanisms to legged robots and developed a bipedal robot combining robustness and compliance, including a life-size humanoid leg robot, gravity compensation mechanisms, and joint-trajectory optimization exploiting redundant degrees of freedom.
Status: Merged into the Anthropomimetic Foot and Leg project.
Coupled Tendon-Driven Bipedal Robot
2019 – 2025
Overview
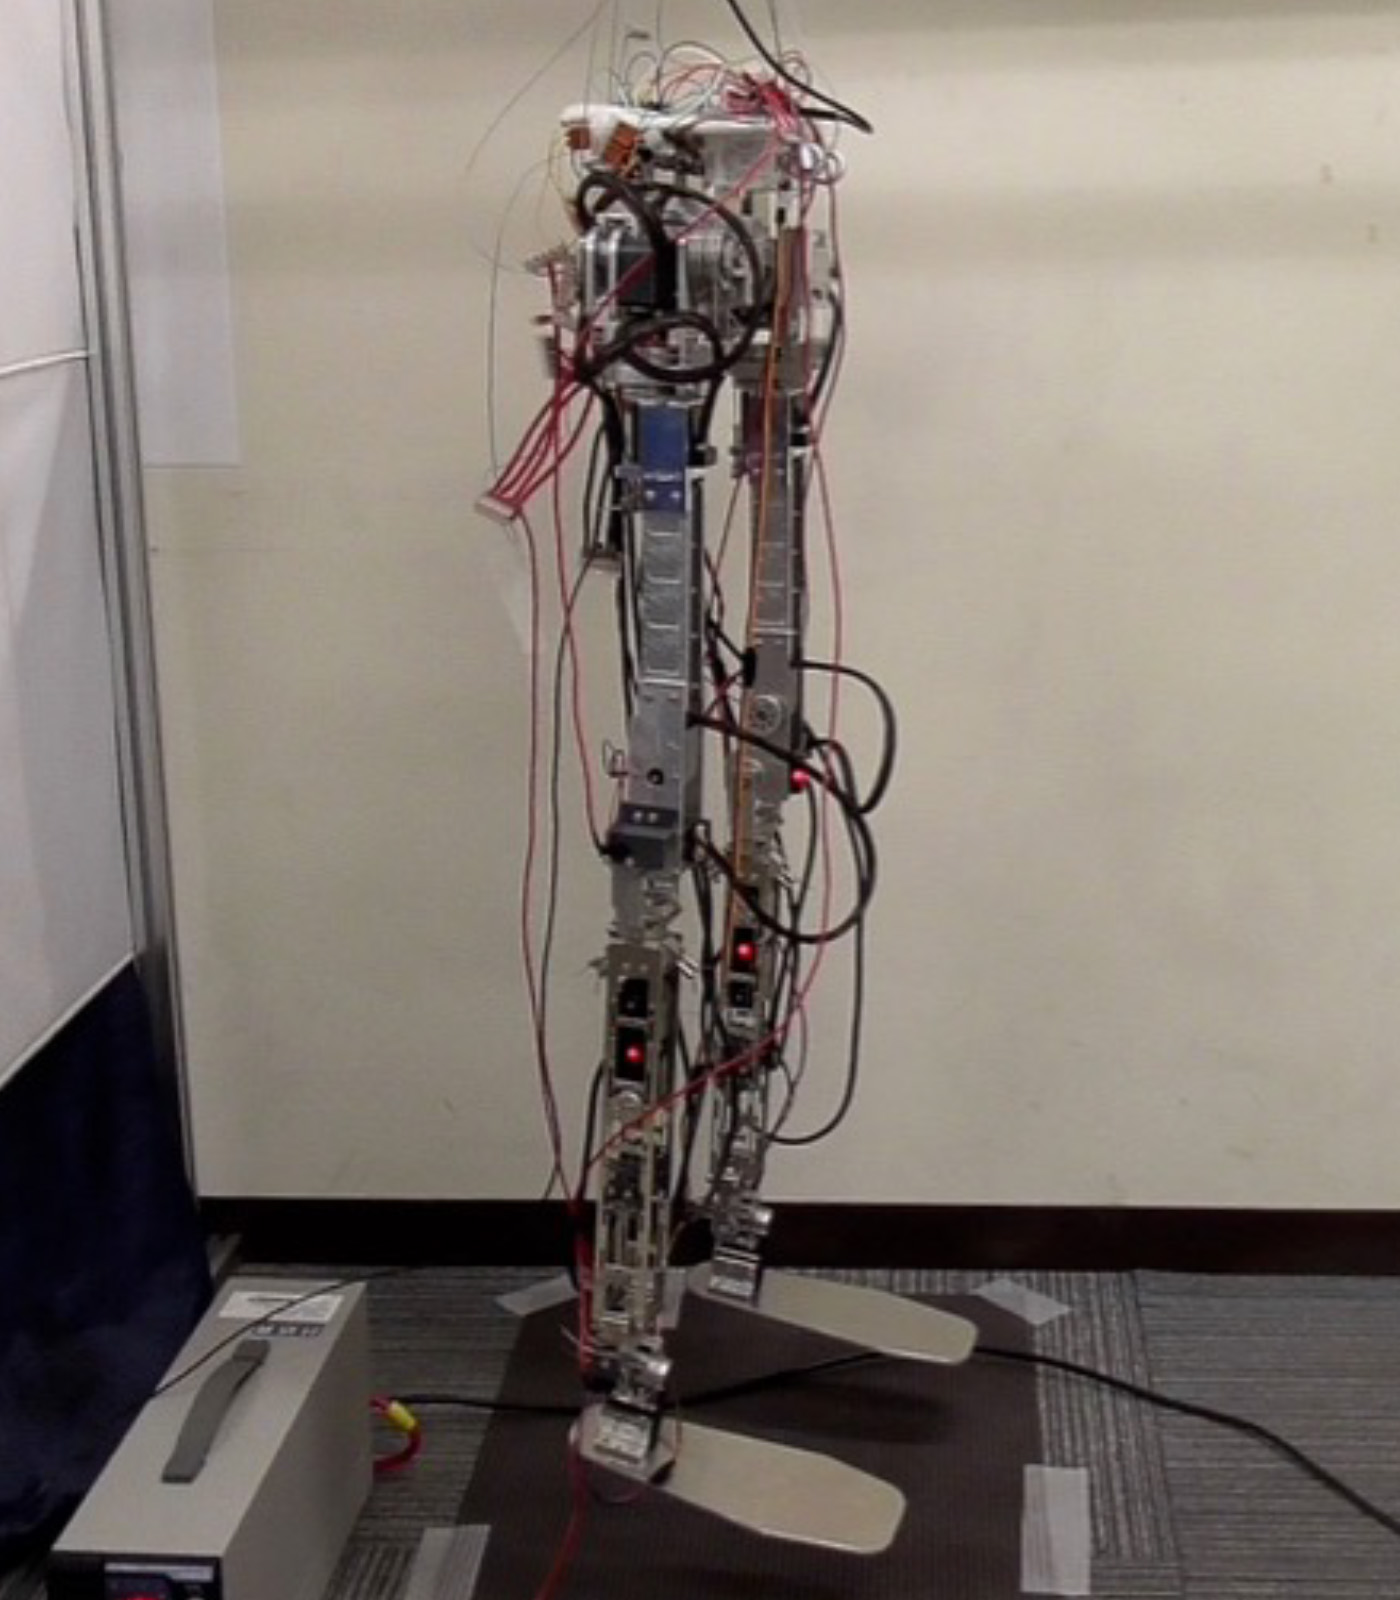
We developed a bipedal robot whose legs use coupled tendon-driven mechanisms. Gravity compensation mechanisms reduce the actuation load, aiming at legged robots that are both robust and compliant.
Technical Features
- Lightweight, high-output leg mechanism using coupled tendon drives
- Gravity compensation mechanisms for the ankle and knee joints
- Development using both a simulator and physical robots
Specifications
- Actuation: coupled tendon drive
- Mechanism: gravity compensation at the ankle and knee
- Environment: physical robot + walking simulator
Results
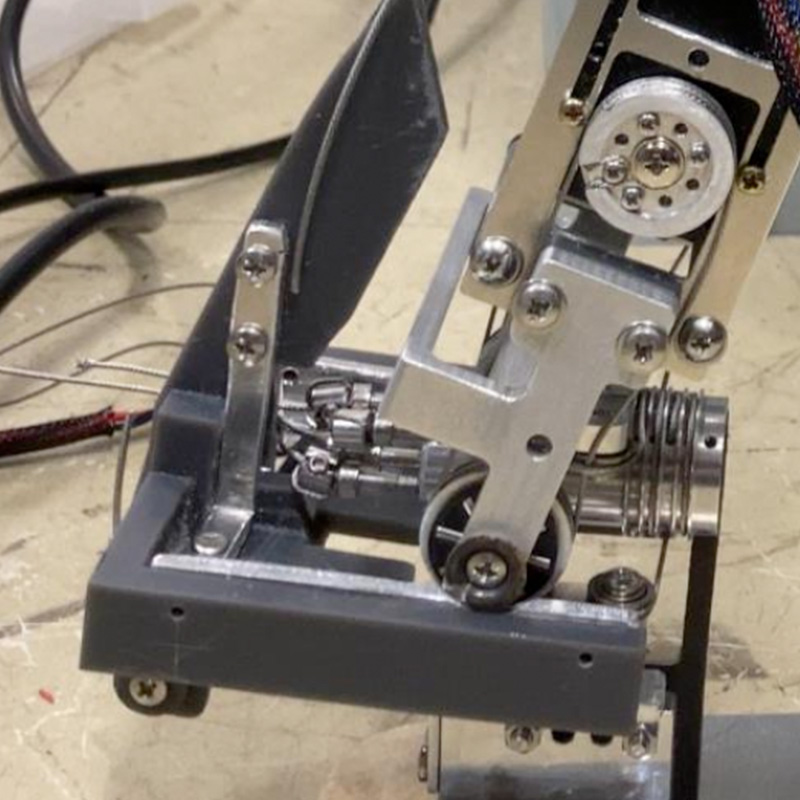
Developed a gravity compensation mechanism for the ankle joint
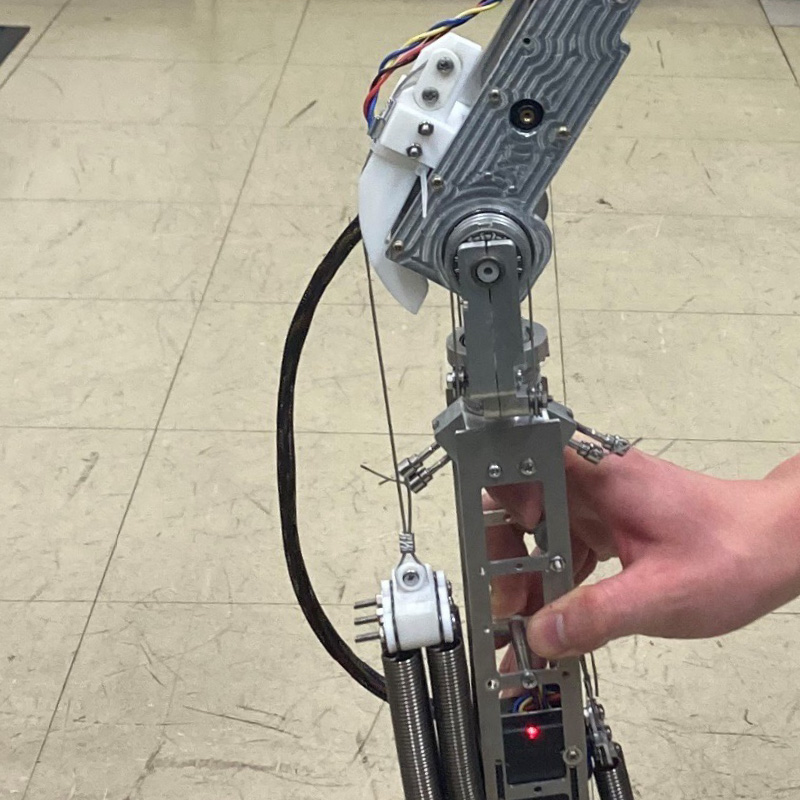
Developed a gravity compensation mechanism for the knee joint
Generated walking motions in simulation
Related Videos (in Japanese)
2020年度 卒論 ワイヤ干渉駆動型脚ロボットの開発
2021年度 卒論 ワイヤ干渉駆動を用いた脚ロボットの重力補償に関する研究
2022年度 卒論 シミュレーションに基づく脚ロボット運動時の負荷トルクに関する研究
2022年度 卒論 ワイヤ干渉駆動を用いた脚ロボットの重力負荷を低減する膝関節機構に関する研究
2023年度 卒論 ワイヤ駆動脚ロボットの歩行制御に関する研究
2025年度 修論 ワイヤ⼲渉駆動型多関節ロボットの冗⻑⾃由度を活⽤した制御法に関する研究